
You can use an ESP32, ST’s VL53L5CX multizone time-of-flight sensor, and an IMU to stream distance measurements and orientation data to a computer, where software renders a live 3D point cloud. It is best understood as an orientation-assisted scanning pipeline—not a proven system for producing a complete, drift-free room model.
What this ESP32 room-mapping project does
The VL53L5CX measures distance across a grid of angular zones. The ESP32 reads those measurements alongside orientation data from a BNO08X-family IMU, then streams the data to a computer. A viewer uses the measurements to display a 3D point cloud as the sensor is moved.
The project’s repository describes the goal as turning a time-of-flight sensor into a 3D scanner: Henrique Ferrolho’s VL53L5CX 3D scanner project. The result described in the available project materials is a live point-cloud visualization. Those materials do not establish a dense, closed room mesh, full simultaneous localization and mapping (SLAM), drift-free position tracking, or independently measured reconstruction accuracy.
What the VL53L5CX measures—and what 8×8 means
The VL53L5CX is a direct time-of-flight (ToF) sensor. It emits infrared light and calculates distance from the light’s return time. Instead of reporting one distance for its whole field of view, it reports distances across multiple zones.
Recommended Free Tools
#1 Best Overall

- The VL53L5CX is an advanced time-of-flight (ToF) multi-area ranging sensor. VL53L5CX uses the latest generation of direct ToF technology from , which enables absolute range measurements regardless of target color and reflectance. It offers accurate ranging up to 400 cm and can operate at high speeds (60 Hz), making it the fastest multi-zone micro-type ToF sensor on the market.
- The VL53L5CX has a wide range of applications. It mainly includes mobile phones, computers, household robots, smart appliances, smart door locks, access control, transportation, shelves, vending machines, smart buildings, smart agriculture, smart medical care and so on.
- The functions of VL53L5CX mainly include ranging, presence detection, proximity detection, ambient light detection, reflectivity detection, multi area detection and 3D detection
- Compared with vl53l0x, the VL53L5 has achieved several breakthroughs: first, it has a large angle, extending to 61 degrees; Second, it can be cut to 16 areas
- Package:2pcs VL53L5X VL53L5CX V2 Range Sensor with Cover
It supports 4×4 or 8×8 output. In 8×8 mode, the 64 zones provide angular samples, not a dense, camera-like depth image. ST lists a 65° diagonal field of view, a range of up to 400 cm, and capability of up to 60 Hz on its VL53L5CX product page. These are manufacturer specifications, not verified performance figures for the complete ESP32 build; achievable range and update rate depend on configuration and conditions. The VL53L5CX datasheet is the primary reference for device behavior.
How the IMU helps—and why orientation is not position
The project uses a BNO08X-family IMU’s game rotation vector to obtain orientation. That can help orient successive distance grids as the sensor turns. It does not, by itself, tell the system the sensor’s absolute location or how far it has translated through a room.
Rank #2
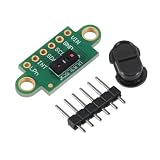
- The VL53L5CX is an advanced time-of-flight (ToF) multi-area ranging sensor. VL53L5CX uses the latest generation of direct ToF technology from , which enables absolute range measurements regardless of target color and reflectance. It offers accurate ranging up to 400 cm and can operate at high speeds (60 Hz), making it the fastest multi-zone micro-type ToF sensor on the market.
- The VL53L5CX has a wide range of applications. It mainly includes mobile phones, computers, household robots, smart appliances, smart door locks, access control, transportation, shelves, vending machines, smart buildings, smart agriculture, smart medical care and so on.
- The functions of VL53L5CX mainly include ranging, presence detection, proximity detection, ambient light detection, reflectivity detection, multi area detection and 3D detection
- Compared with vl53l0x, the VL53L5 has achieved several breakthroughs: first, it has a large angle, extending to 61 degrees; Second, it can be cut to 16 areas
- Package:1pcs VL53L5X VL53L5CX V2 Range Sensor with Cover
Combining grids while moving the sensor can create a point cloud, but orientation data alone does not establish drift-free translational tracking. A visually convincing cloud is therefore not proof of a metrically stable, complete room reconstruction.
How the data pipeline is configured
In the showcased firmware, the VL53L5CX is configured for 8×8 ranging at 15 Hz. The BNO08X game rotation vector is requested with a 10 ms interval, or 100 Hz. These are settings in the project firmware, not independently measured rates or a benchmark of end-to-end display latency.
The Tool Desk
Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →Outbyte PC Repair FREEClear out junk files and repair common Windows errorsFree Scan →Rank #3

- 2pcs VL53L5X VL53L5CX V2 Range Sensor with Cover
The ESP32 reads the sensors and streams data to a connected computer; the computer-side viewer renders the measurements as a point cloud. Filtering and plane fitting may help make a visualization easier to interpret, but do not, on their own, demonstrate globally consistent room mapping.
ESP32 setup details to check
Sensor timing, resolution, I²C wiring, and memory requirements can depend on the specific driver, ESP32 variant, and breakout boards. The following notes apply to the cited Espressif component example, not automatically to every implementation.
Rank #4

- 2-Piece Package Set:This package includes 2 Range Sensor with Cover providing basic components for daily assembly use.
- Basic Accessory Matching:Equipped with corresponding pin headers, which can be used for basic connection and assembly operations according to personal needs.
- Simple Assembly Structure:The module has a simple structure, which is convenient for basic wiring and installation, suitable for daily electronic assembly practice.
- With Protective Cover:Each module is fitted with a small protective cover, which can cover the surface area for basic daily protection during placement.
- Universal DIY Use:Suitable for daily electronic DIY assembly, learning practice, and matching with common development boards for basic experimental use.
- Resolution and timing: The example supports 4×4 and 8×8 output. It notes that ranging frequency depends on resolution and that integration time must fit within the ranging period for the selected configuration.
- I²C address: The example documents 0x52 as the sensor’s default I²C address. Confirm the address for the chosen module and any board-level configuration.
- Task stack: The example recommends at least 7168 bytes for the main task stack to avoid stack overflow in that setup.
- Component version: These details come from version 4.0.0 of the Espressif Component Registry VL53L5CX example. A separate version 4.0.1 component README provides an ESP32-S3 wiring example. Verify the instructions against the component version and hardware you use.
- IMU initialization: The showcased project tries BNO08X I²C addresses 0x4A and 0x4B and enables the game rotation vector at a 10 ms interval. These are project implementation details, not universal requirements for every board.
Before powering the circuit, verify the pinout, voltage and I²C requirements of the exact VL53L5CX and BNO08X breakouts, as well as the ESP32 board. The example wiring does not establish compatibility with every module.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.What to expect from the point cloud
The output is useful as a live, sparse spatial visualization: it can show measured surfaces while the sensor is directed around a space. Its angular sampling is limited by the sensor’s 16- or 64-zone output, and the quality of a room-wide result also depends on how measurements are combined as the sensor moves.
Best Value
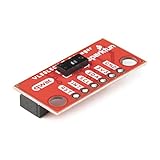
- The SparkFun Qwiic Mini ToF Imager is built around VL53L5CX from ST Electronics; a state of the art, Time-of-Flight (ToF), multi zone ranging sensor. Multizone ranging output with either 4x4 or 8x8 separate zones
- This chip integrates a SPAD array, physical infrared filters, and diffractive optical elements (DOE) to achieve the best ranging performance in various ambient lighting conditions with a range of cover glass materials.
- Autonomous Low-power mode with interrupt programmable threshold to wake up the host; Up to 400cm ranging; 60Hz frame rate capability; I2C Address: 0x52; Operating Voltage: 3.3V; 2x Vertical Qwiic Connectors
- Emitter: 940nm invisible light vertical cavity surface emitting laser (VCSEL) and integrated analog driver; 63° diagonal square FoV using diffractive optical elements (DOE) on both transmitter and receiver; Dimensions - 0.5in. x 1in.
- Note: The VL53L5CX is unique in that it requires its firmware to be loaded at power-on over the I2C bus. Because this firmware is ~90k bytes, we recommend a microcontroller with enough flash to store VL53L5CX's firmware as well as your program code. Sorry, Uno's are out. But didn't you want an excuse to try out something new? We recommend choosing either an Artemis Thing Plus or an ESP32 Thing Plus board as your development board.
The available project coverage does not provide an independent accuracy test or controlled measurement of the complete system’s latency. ST’s range and frequency figures describe the sensor’s capabilities, not the accuracy or completeness of the resulting map. A dependable, metrically stable room model would require evidence for tracking and reconstruction beyond the orientation-assisted point-cloud pipeline documented here.
Quick Recap
Is this build a fit for your project?
- Consider it if you want an embedded sensor project that streams multizone distance readings and orientation to a computer for live 3D visualization.
- Check carefully if your application depends on a particular sampling density, update rate, working range, driver version, or ESP32 wiring: these depend on configuration and hardware.
- Look beyond this build if you need a complete room mesh, absolute position, drift-free tracking, or validated dimensional accuracy. The documented point-cloud demonstration does not establish those capabilities.
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

