
Elephant Robotics documents a Docker workflow for running its mycobot_ros package, but that workflow forwards graphical output to the host with X11; it does not provide a browser-based noVNC desktop. To reach a ROS desktop through a browser, you need a separately configured VNC server and noVNC/websockify layer inside or alongside the container. The vendor’s robot-side VNC instructions are a third, separate setup.
This guide separates the documented ROS baseline from the noVNC pieces you must configure and validate for your chosen image. The repository’s default Docker launch targets a myCobot 320, so verify your arm model, controller, firmware, ROS distribution, and connection method before connecting physical hardware.
What the official Docker setup provides
Elephant Robotics’ mycobot_ros repository documents a Docker and Docker Compose route for running its ROS package. Its Docker examples build a ROS image, allow the local root user to connect to the host X display with xhost +local:root, and start a service. The default launch runs roslaunch mycobot_320 mycobot_320_slider.launch.
This is host X display forwarding, not noVNC: the graphical application is displayed through the host’s X server rather than a browser-accessible desktop. The README also lists NVIDIA service variants; use the matching service defined by the repository if following its GPU path. The documented non-NVIDIA examples are the baseline when no NVIDIA GPU service is needed.
#1 Best Overall
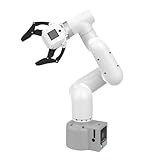
- Enhance your project capabilities with myCobot: The M5 version of the robot arm uses Esp32 as the core processor, two screens and multiple physical buttons, and can be used on the ground the size of a desk. Deeply integrated with the M5 expensive ecosystem, users can follow the tutorials provided by Yahboom to control the robot through UIFlow, Python, and Arduino.
- ROS support: Developed in ROS, the world's mainstream robot communication framework, myPalletizer can be controlled in a virtual environment and algorithm verification can be performed, which reduces the requirements for the experimental environment and improves experimental efficiency.
- Excellent configuration: 24V industrial electrical interface to meet your industrial scene development needs, button interaction, screen display, and PLC interface, allowing you to quickly and safely build robotic arm application exploration scenarios. With a 350mm working radius, 1000g payload and 1mm repeatability, the myCobot 320 robotic arm is the ideal solution for your scene exploration needs.
- DIY your personal mechanical assistant: open ROS simulation development environment, built-in kinematics forward and inverse solution algorithms, equipped with up to 12 standard 24V industrial I/O interfaces, expandable to develop PLC control independent programming, supports mainstream control interfaces, rich Terminal expansion accessories help explore the boundaries of personal applications.
- Open source interface, secondary development:Based on different types of applications, the interface is open sourced and can realize object recognition, face recognition, image recognition, etc. Easily learn to program myCobot in your style and get ready to start your robotics journey.
The repository’s ROS 1 support notes list Ubuntu 16.04 with ROS Kinetic, Ubuntu 18.04 with ROS Melodic, and Ubuntu 20.04 with ROS Noetic. These are the README’s stated combinations, not a guarantee of current operating-system lifecycle support or compatibility of every branch and model.
What noVNC adds—and what remains to configure
noVNC provides browser access to a VNC desktop, but it needs a VNC server and a WebSocket bridge such as websockify, plus network exposure and a browser endpoint. The official ROS Docker README does not specify a noVNC image, Dockerfile changes, desktop packages, VNC server, websockify command, port mapping, or browser URL. Those implementation details therefore depend on the image and container configuration you select; they should not be treated as vendor-provided settings.
For a browser-based environment, keep the ROS container’s responsibilities distinct from the display layer. You must choose and validate how the desktop starts, how its VNC server is secured and made reachable, and how noVNC/websockify connects to it. Do not assume that adding a port mapping alone creates a working browser desktop. Until those pieces are verified for the chosen image, the vendor-supported setup remains the X-forwarding workflow above.
Run the documented ROS Docker baseline
- Check the repository’s current instructions. Open the mycobot_ros README and select the ROS distribution and service variant that match your environment. The repository describes Docker and Docker Compose as requirements for its Docker route.
- Build the image. Run the build command documented for the selected service in the repository. The README’s flow builds the container before starting it.
- Allow host X output if you are using the documented display method. Run
xhost +local:rooton the host as shown by the README. This grants local root access to the X display; it is not a noVNC configuration step. - Start the service. Use the repository’s documented Compose command and service name for your selected ROS/GPU variant. The default launch target is the myCobot 320 slider launch file, so confirm that target is appropriate before connecting an arm.
Do not substitute guessed Compose service names, ports, or noVNC commands: they are specific to the selected repository revision and image, and the official README does not supply noVNC settings.
Rank #2
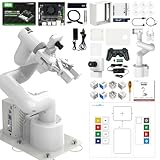
- 【3 Master Control】Three master controls to choose from, one for educational robotic arms that seamlessly integrates with the Jetson Nano/Orin Nano Super/Orin NX Super ecosystem.Build and run Ubuntu 22.04 based on 3 main controls, making it an ideal development tool for developing robots and programming.Equipped with Orin Nano Super and Orin NX Super, it supports multiple fields such as robot algorithm development and ROS simulation learning.
- 【UR-type mechanical structure】The 7axis collaborative robot developed for user-defined programming has greater flexibility than traditional robotic arms.The smooth body and adaptive gripper have a larger range of motion and can reach more and more precise positioning.Using AI to control its movement and speed, it can achieve millimeter-level positioning and operation.It can work safely with people,is compact, and has many interfaces,making it a collaborative partner on your desktop.
- 【Programmable&ROS system】Explore the possibilities of RoboFlow,the industrial robot software of elephan-t robot.Relying on the original Jetson Nano open source ecosystem,Jetcobot provides rich development interfaces, Python driver libraries and built-in ROS environment to make your development easier and faster. It supports multiple programming languages, various software interaction methods and is for a wide range of app. Explore the unlimited potential of this collaborative robot arm.
- 【AI Vision&Remote Control】Equipped with wooden blocks and stickers,it can realize recognition, tracking, and grasping actions, fully reflecting the AI-Type characteristics of the robot arm. Most functions can be operated through a multi-function app (Android);equipped with a USB game controller remote control to achieve the best control experience;create Jupyter Lab pages online.The APP cannot control the gripper,it is recommended to use a USB controller.
- 【Tutorials】All information and instructions are in English.We provide high-quality technical support services. If you need help, please contact Yahboom.Jetcobot is recommended for individuals with a basic understanding of programming, not for beginners.Considering the threshold of product use,we strongly recommend that you read the instructions carefully before operation.Please pay attention to the power adapters in the list.If you use them interchangeably, they will burn out.
Choose the right display-access method
| Method | What it connects to | What the vendor documentation establishes |
|---|---|---|
| Host X forwarding | ROS graphical applications in the Docker container, displayed through the host’s X server | The ROS repository documents the Docker flow and xhost +local:root. |
| Robot-side VNC | The system running on a myCobot 320 Pi, reached over the network using a VNC viewer | The myCobot 320 Pi system instructions describe same-Wi-Fi access using the robot’s IP or access through its hotspot at 10.42.0.1. |
| noVNC with Docker | A containerized desktop reached through a web browser | The cited ROS Docker instructions do not establish the image, VNC server, websockify configuration, port mapping, or browser URL. Configure and validate these for your chosen implementation. |
The 320 Pi VNC instructions are for accessing the robot’s own system. They do not configure a VNC server or noVNC inside the ROS container.
Check ROS dependencies and hardware compatibility
Elephant Robotics’ ROS environment building guide identifies ROS and MoveIt as dependencies and describes pymycobot as the API used to interact with a real robot. The repository separately documents a local-install route, including installing the Python API with pip install pymycobot --user and building the repository. That local route is not a substitute for the Docker instructions; follow the path matching how you intend to run the package.
The myCobot repository lists multiple product families, including 280 and 320, while the ROS Docker example defaults to a 320 launch target. Do not assume that model families or controller variants use identical ROS launch files, ports, firmware, or connection settings. The ROS repository also notes firmware requirements for the Atom and base controller; use the documentation for your exact hardware variant to confirm supported firmware and connection details before controlling an arm.
Quick Recap
- Confirm the arm model and controller variant, rather than relying on the generic myCobot name.
- Match the ROS package, launch file, and ROS distribution to that hardware.
- Check the model-specific firmware and connection requirements in its documentation.
- Use the ROS package’s documented setup for hardware communication; the display method does not establish a robot connection by itself.
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.
Quick wins for a faster PC:
Clear out junk files and repair common Windows errorsFree Scan →Scan for outdated or missing drivers - takes under a minuteDriver Scan →Repair Windows errors before they cause bigger problemsFix Now →
