
An ESP32-CAM surveillance car is a small Wi-Fi-controlled robot that streams live camera video while you drive it from a browser or phone. The ESP32-CAM handles the camera and wireless interface; a dual H-bridge drives the motors. This guide covers the parts, power and wiring decisions, programming, controls, and trade-offs behind a practical ESP32-CAM RC car with live video.
What an ESP32-CAM robot car does
The AI-Thinker ESP32-CAM with its OV2640 camera can host a control page and deliver a live video stream over Wi-Fi. A separate motor driver receives movement commands and switches power to the DC gear motors. In the vitorccs implementation, the browser page uses a virtual joystick, with optional keyboard input; the AK-Homberger project adds controls for speed, flash, still images, stream quality, and a servo. [vitorccs project] [AK-Homberger project]
That division matters: the ESP32-CAM is the camera and Wi-Fi controller, not a motor power stage. The motors need a dual H-bridge, and the camera board needs a stable regulated supply. A phone can display the stream while sending steering commands, but the available implementations differ in interface and features.
Parts and build choices
Essential components
- AI-Thinker ESP32-CAM board with OV2640 camera.
- A 2WD or 4WD chassis with wheels and two or four 3–6 V DC gear motors. The vitorccs parts list specifies two 18650 cells for its motor battery pack; that is a project-specific example, not a universal battery prescription. [vitorccs parts list]
- A dual H-bridge motor driver, such as an L298N or DRV8833.
- A motor battery pack, holder, switch, wiring, and any bulk capacitors specified for the chosen driver and build.
- A regulated 5 V supply for the ESP32-CAM.
- An FTDI/FT232RL USB-to-serial adapter for initial programming.
Optional additions
- An external antenna, if appropriate for the board and intended setup.
- An OV2640 wide-angle lens for a broader view.
- A servo mount for pan or tilt control.
- LEDs or use of the onboard flash LED where the selected design supports it.
Choose the motor driver
The vitorccs project describes the L298N as the straightforward build option and the DRV8833 as a more efficient alternative. Its documentation gives approximate voltage drops of 2–4 V for the L298N bipolar design and 0.2–0.4 V for the DRV8833 MOSFET design. Those are the project author’s component figures, not independent test results; actual behavior depends on the hardware and operating conditions. A lower driver voltage drop generally leaves more of the battery voltage available to the motors and reduces driver heating. [vitorccs driver notes]
Quick wins for a faster PC:
Scan for outdated or missing drivers - takes under a minuteDriver Scan →Repair Windows errors before they cause bigger problemsFix Now →#1 Best Overall
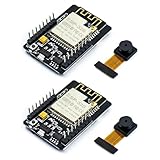
- ESP32CAM is based on ESP32 chip and OV camera module, use low-power dual-core 32-bit CPU, which can be used as an application processor.
- The main frequency is up to 240MHz, and the computing power is up to 600 DMIPS.
- Built-in 520 KB SRAM , external 8MB PSRAM ,support UART/SPI/I2C/PWM/ADC/DAC and other interfaces;Support picture wireless upload, TF card, multiple sleep modes, STA/AP/STA+AP working mode, secondary development.
- It is an ideal solution for IoT applications. The ESP-32CAM comes in a DIP package that plugs directly into the backplane for rapid production.
- ESP-32CAM can be widely used in various IoT applications. Suitable for home smart devices, industrial wireless control, wireless monitoring, QR wireless identification, wireless positioning system signals, etc.
| Choice | Practical trade-off |
|---|---|
| L298N | The documented simpler path, but its higher stated voltage drop can mean less voltage at the motors and more heat. |
| DRV8833 | The documented efficiency upgrade, with a lower stated voltage drop; confirm that the specific driver board supports your motors and wiring. |
| 2WD chassis | Uses two motors and is simpler; it may provide less traction than a four-motor build. |
| 4WD chassis | Can offer more traction, but four motors increase current demand and make battery and driver sizing more important. |
Do not select a driver only by its name. Check the exact board’s motor-voltage and current limits against the motors, and follow that board’s wiring documentation.
Plan power and wiring before assembly
Motor startup and changing loads can cause electrical noise or voltage dips that reset the ESP32-CAM. A separate motor battery and regulated 5 V camera supply, or a suitable converter arrangement, can reduce brownouts. The RoboLink example uses a motor battery pack and a separate 5 V supply or regulator for the camera board. Keep grounds connected as required by the circuit so control signals have a common reference, and place any bulk capacitors as specified by the build and driver documentation. [RoboLink tutorial] [vitorccs build notes]
Rank #2

- Package included:2pcs ESP32-CAM-MB Camera Module and 2pcs USB-TTL Serial Adapter Module.Compared with the old model, it does not require complex wiring and supports manual and automatic downloads
- HK-ESP32-CAM-MB adopts Micro USB interface, convenient and reliable connection method, convenient to apply to various IoT hardware terminal occasions
- HK-ESP32-CAM-MB module can work independently as the smallest system
- A new W-BT dual-mode development board based on ESP32 design, using PCB on-board antenna, with 2 high-performance 32-bit LX6CPU, using 7-level pipeline architecture, main frequency adjustment range 80MHz to 240Mhz
- Ultra-low power consumption, deep sleep current is as low as 6mA. It is an ultra-small 802.11b/g/n W+ BT/BLE SoC module -->>Our technical service team is always ready to answer your questions. please feel free to contact us--)
- Verify the exact AI-Thinker pin map and motor-driver board before applying power; pin assignments are design-specific.
- In the RoboLink example, GPIO 4 drives the onboard flash LED and is used by the camera, so that design does not assign it to motor control. [RoboLink wiring guidance]
- Keep the camera’s regulated 5 V rail within the board’s requirements. Do not assume the motor supply is a suitable camera supply.
- Check polarity, common ground, motor-driver connections, and the battery arrangement before powering the assembled car.
Flash the ESP32-CAM
The AK-Homberger instructions use an FTDI adapter set to 5 V, crossed RX/TX connections, a common ground, and IO0 connected to ground during upload. After programming, release IO0 from ground and reset the board for normal boot. Follow the project’s instructions for the exact adapter and board; do not leave the upload-mode connection in place when you expect normal operation. [AK-Homberger programming instructions]
- Connect the FTDI adapter’s TX to the ESP32-CAM RX and its RX to the board TX; connect grounds together.
- Set the adapter to 5 V as specified by the project, and connect IO0 to ground to enter upload mode.
- Upload the project firmware using its stated procedure.
- Disconnect IO0 from ground and reset the board to boot normally.
Control the car and view live video
A browser-based interface is a convenient route when the firmware hosts a page on the ESP32-CAM. The vitorccs project uses a virtual joystick and optional keyboard control. The AK-Homberger interface includes stream start, speed, flash, still-image, quality or resolution, and servo controls. These are project-specific interface features, not guaranteed functions of every ESP32-CAM car. [vitorccs controls] [AK-Homberger controls]
Free tools Windows power users keep installed
One-click scans. No signup required.
Rank #3
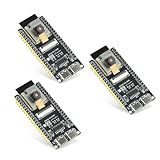
- Dual-core processor: The ESP32 module is based on the powerful ESP32-S3-WROOM N16R8 module and is equipped with a dual-core 32-bit LX7 processor. Its excellent AI computing performance, real-time processing capabilities, and low power consumption make it ideal for image recognition, edge AI, and complex IoT applications
- Integrated 2-megapixel OV3660 camera: Built-in OV3660 camera to capture clear images and stream video in real time. Perfect for smart surveillance, face recognition, and AI-based computer vision projects. It is the preferred solution for DIY makers and professionals to build camera-enabled IoT systems
- Dual Type-C ports for OTG and serial debugging: Designed with two USB Type-C interfaces - one supports USB OTG for host/device functions, and the other provides TTL serial for easy programming and debugging
- Shared antenna: Supports IEEE 802.11b/g/n Wi-Fi (2.4GHz) and Bluetooth 5 (LE and Mesh), using shared antennas to optimize wireless performance. Enhanced 2 Mbps PHY and long-distance communication (Coded PHY) ensure stable multitasking in harsh environments
- Multi-scenario applications: The ESP32 S3 development board maintains high stability even at high temperatures, making it ideal for industrial environments, educational purposes, and AI-driven projects. It is a versatile choice for robots, smart devices, and machine vision in lab or field applications
Another pattern is a phone app for movement commands with video displayed in a separate camera view. RoboLink’s tutorial demonstrates phone joystick control over Wi-Fi UDP while an MJPEG stream appears in a camera widget. [RoboLink control and video example]
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.What to expect from the design
Camera coverage
A fixed camera is mechanically simple but looks in only one direction. A pan/tilt servo mount can widen the area you inspect without turning the chassis, at the cost of extra hardware, wiring, and control setup. Whether servo controls are available depends on the chosen firmware.
Rank #4

- Dual core: Upgraded ESP32 CAM module equipped with a powerful dual-core processor, 32-bit dual-core CPU with low power consumption. The main frequency is up to 240 MHz, and the computing power is up to 600 DMIPS; integrated 520 KB SRAM, external 4 MB PSRAM.
- Flexible extension: ESP cam supports UART/SPI/I2C/PWM/ADC/DAC and other interfaces. Supports OV7670 and OV2640 cameras, built-in flash.
- Low performance: For ESP32 cam with antennas. Very low power consumption, deep sleep current is as low as 6mA. It is an ultra-small 802.11b/g/n Wi-Fi + BT/BLE module. Supports STA/AP/STA+AP working mode. USB to serial port CH340G
- Easy to use: for ESP32-CAM-MB is a small camera module, with on-board PCB antenna, convenient connection. With the built-in development card and TF card slot, it is easy to set up your project and start working.
- Wide application: OV2640 supports the energy-saving Internet of Things (IoT). The ESP32 module supports image transmission for smart household appliances, wireless monitoring, wireless positioning systems, etc.
Driving layout and power
Two-wheel drive can keep the build simpler; four-wheel drive may improve traction but raises current demand. Likewise, separating or regulating camera power adds wiring complexity but can help isolate the camera from motor-related dips. Choose based on the chassis, motors, battery, and driver actually being used rather than assuming one arrangement fits every build.
Performance varies by build
Runtime, Wi-Fi range, control latency, and frame rate depend on the motors, batteries, camera resolution, wireless conditions, and firmware. The cited projects do not provide a comparable benchmark for those measures, so a particular runtime or range cannot be promised from the design description alone.
The Tool Desk
Outbyte PC Repair FREEClear out junk files and repair common Windows errorsFree Scan →Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

