
The Tool Desk
Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →To trace a CAN fault in an AUTOSAR ECU, start at the application behavior and follow the configured path through the RTE and Basic Software (BSW) toward the CAN interface and controller. For a UDS diagnostic request received over CAN, the key path is typically CAN driver → CanIf → PduR → CanTp → Dcm; the response travels back through the corresponding lower layers. Signal communication follows a related but distinct path involving Com. Locating the first boundary where expected behavior changes is more useful than treating “the CAN stack” as one component.
How AUTOSAR’s layers help isolate a CAN fault
AUTOSAR separates application software from hardware-facing communication details. The application layer contains software components (SWCs); the Runtime Environment (RTE) mediates their communication with one another and with services below. Beneath the RTE, the microcontroller abstraction, ECU abstraction, and service layers are commonly grouped as Basic Software (BSW). This layered arrangement helps identify which interface or responsibility to inspect when a CAN symptom appears.
- Application layer: SWC behavior, such as producing or consuming a signal, or requesting a diagnostic operation.
- RTE: generated interfaces and connections between SWCs and the services they use.
- Service layer and communication services: higher-level communication and diagnostic functions, including Com, PduR, CanTp, Dcm, and Dem.
- ECU abstraction and microcontroller abstraction: interfaces that lead toward the ECU’s hardware and microcontroller-specific drivers. The MCAL and CAN driver are hardware-dependent; upper interfaces are intended to hide more of those details.
The AUTOSAR R24-11 layered-architecture document is the current reference identified here for layer responsibilities. Renesas’ layer overview and EE Times’ architecture explanation describe the same general separation. The practical implication is to trace the failing data or request across boundaries, rather than assuming that a symptom seen by an application must originate in application code.
Which AUTOSAR modules handle CAN signals and UDS requests?
For a diagnostic request carried over CAN, a useful receive-side chain is CAN hardware and driver, CanIf, PduR, CanTp, then Dcm. This is a diagnostic path, not the only route taken by every CAN message. Signal communication uses Com for application I-PDUs and signals; PduR handles configured routing between relevant modules.
#1 Best Overall

- CAN J1939 Deutsch Adapter Cable;DB9 To J1939 Connector Cable;J1939 to DB9 Adapter Cable ; Expansion of Diagnostic Interface,CAN SAE J1939;Truck Diagnostic Tool; 1Meter
- Suitable for heavy-duty truck maintenance technicians and vehicle networking R&D engineers, used for CAN data acquisition and ECU diagnosis of trucks, buses, and construction machinery
- Supports standard J1939 protocol, designed specifically for CANedge data loggers; Built in multi-layer shielding layer to resist electromagnetic interference, ensuring zero loss in signal transmission; High compatibility interface suitable for mainstream heavy equipment such as Caterpillar and Cummins
- The interface adopts gold plating technology, which is resistant to pulling, inserting, and oxidation; The Deutsch connector housing is made of high-temperature resistant engineering nylon, which is sturdy and slip resistant; DB9 end is equipped with double-sided metal hand screws, and the wire is made of flame-retardant PVC outer coating
- [Usage]: 1 Align the Deutsch 9-pin male head with the vehicle OBD diagnostic port (usually green or black interface) and rotate it to lock it; 2. Connect the DB9 female head on the other end to the D-Sub 9 interface of the CAN recorder or OBD scanner; 3. Rotate the long screws on both sides of DB9 clockwise until they are completely fixed; 4. Turn on the vehicle ignition switch and read the SAE J1939 data stream in real-time through the terminal connection
| Module or boundary | Role in tracing a CAN issue |
|---|---|
| CAN driver and CAN hardware | At the hardware-facing end of the path; inspect when expected frames do not reach the software interface or cannot be transmitted. |
| CanIf | Provides a uniform interface between upper layers and CAN hardware. Infineon describes it as the interface between upper layers and CAN hardware. |
| PduR | Routes I-PDUs among configured communication and diagnostic modules, including CanIf, CanTp, Dcm, and Com. It forwards data; EE Times’ 2010 explanation says it should not modify the I-PDU. |
| CanTp | Handles transport of diagnostic messages over CAN using ISO 15765-2 in the Infineon implementation described. |
| Dcm | Handles diagnostic communication and requests, including UDS service processing. The cited description references ISO 14229-1 as well as ISO 15031-5, ISO 15765-4, and SAE J1979. |
| Com | Handles application I-PDUs and signals; check it when a CAN frame is present but the expected application signal is absent, incorrect, or stale. |
| Dem | Manages diagnostic events and trouble-code data, including associated freeze-frame or extended data; inspect it for DTC qualification, status, or retention symptoms. |
For signal-based communication, do not force every fault through CanTp and Dcm: those modules belong to the diagnostic transport and request path. Follow the actual configured PDU and signal route instead.
How do you trace a UDS request from CAN to Dcm?
- Confirm reception at the CAN interface. Establish whether the expected CAN frame reaches the ECU’s CAN hardware and driver. If it does not, investigate the bus, controller configuration, and hardware-facing driver path before moving upward.
- Check CanIf and PduR configuration. Verify that the received CAN information is exposed through CanIf and that the configured PDU route forwards it toward the intended upper module. A routing error is a stronger lead than changing SWC logic when the request disappears between interfaces.
- Check CanTp transport behavior. If the request requires transport handling, inspect segmentation, reassembly, and flow-control behavior. A frame-level trace may show traffic while the complete diagnostic message still fails to arrive.
- Check Dcm request handling. If the complete request reaches Dcm, inspect the configured session, service permissions, timing, and response handling. EE Times describes Dcm in terms of three function blocks: Diagnostic Session Layer (DSL), Diagnostic Service Dispatcher (DSD), and Diagnostic Service Processing (DSP).
- Trace the response in reverse. If Dcm processes the request but the tester receives no response, follow the configured transmit path back through CanTp, PduR, CanIf, and the CAN driver. Determine the first layer at which the response is missing or differs from expectation.
Use the ECU’s generated configuration and project-specific mappings when checking routes and interfaces: AUTOSAR module responsibilities define what to investigate, but the actual PDU IDs, connections, and settings depend on the ECU configuration.
Rank #2
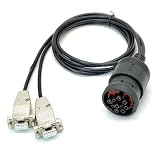
- CAN Cable, J1939 DEUTSCH Connector to Dual DB9, One Two Expansion of Diagnostic Interface, CAN to J1939 Cable with DEUTSCH Connector;CAN SAE J1939;Truck Diagnostic Tool; 1Meter
- Supports Dual CAN channels, capable of simultaneously recording data from both the main J1939 network and the auxiliary J1939 network; Equipped with multi-layer shielding technology to effectively resist electromagnetic interference; Adapt to mainstream data loggers such as CANedge, achieve a one to two expansion of heavy-duty vehicle diagnostic interfaces, and provide access to multiple J1939 networks through a single Deutsch 9-pin connector
- Suitable for heavy-duty truck maintenance technicians and vehicle networking R&D engineers, used for CAN data reading and monitoring of heavy-duty vehicles (trucks, buses, tractors, etc.) and industrial equipment.
- The interface adopts gold plating technology, which is resistant to oxidation and has stable conductivity; The DB9 joint is reinforced with injection molding, which is resistant to tension, tearing, and wear; The shell is equipped with CAN1/CAN2 laser engraved markings for easy identification of channels; Select high specification flame-retardant wire
- [Usage]: 1 Insert the Deutsch 9-pin male connector into the vehicle diagnostic interface (usually located below the dashboard in the driver's cabin); 2. Connect the DB9 female head labeled CAN1 to the main channel of the data logger; 3. Connect the DB9 female head labeled CAN2 to the secondary channel or the second monitoring device; 4. Tighten the hand screws on both sides of DB9 to ensure a stable physical connection; 5. Start the vehicle power supply and read J1939 protocol data through the recorder
How can you distinguish an application, RTE, routing, transport, or DCM fault?
| Observed symptom | First boundary to examine | Useful checks |
|---|---|---|
| CAN frame arrives, but an application signal is missing or wrong | Com, PDU routing, then RTE and SWC interface | Confirm the configured PDU and signal mapping, the PduR route, the RTE sender/receiver connection, and the SWC’s expected data. |
| Diagnostic request is visible as CAN traffic but no complete request reaches Dcm | CanIf, PduR, and CanTp | Check interface delivery and routing first; then examine transport segmentation, reassembly, and flow control. |
| Complete UDS request reaches Dcm but the service is rejected or response is unexpected | Dcm | Check session state, service permissions, timing, and response handling. |
| Tester receives no response although Dcm handles the request | Transmit-side path below Dcm | Trace the response through CanTp, PduR, CanIf, and the CAN driver to find where it stops. |
| DTC is absent, has unexpected status, or does not persist as expected | Dem and fault-memory storage path | Inspect event qualification, DTC status, freeze-frame or extended data, and NVRAM persistence. |
| Application-level operation fails despite apparently valid lower-layer traffic | RTE contract and SWC boundary | Check ports, sender/receiver or client/server mapping, and the generated RTE interfaces before changing application behavior. |
These are starting points, not proof of cause: a symptom can cross more than one boundary. Correlate what each layer receives and sends, using the ECU’s configuration and available traces to establish where expected behavior first diverges.
What is a repeatable AUTOSAR CAN fault-isolation workflow?
- Classify the symptom. Decide whether the problem is a missing signal, malformed payload, timeout, rejected diagnostic service, incorrect session, or missing or persistent DTC. This determines which route to trace.
- Check the SWC and RTE contract. Verify the relevant ports, sender/receiver or client/server mapping, and generated RTE interfaces.
- Verify Com/PDU configuration and PduR routing. Confirm that the expected PDU is configured and forwarded to the correct module. Because PduR is a forwarding layer, investigate the route before rewriting application logic when data disappears there.
- Inspect CanTp and the CAN interface. For diagnostic transport symptoms, check segmentation and flow control; for frame-level symptoms, inspect CanIf and the controller-facing path.
- Inspect Dcm for UDS failures. Check session, timing, service permissions, and response handling once the complete request reaches Dcm.
- Inspect Dem for fault-memory issues. Check event qualification, DTC status, freeze-frame or extended data, and NVRAM persistence.
- Compare ECU self-diagnosis with tester results. EE Times distinguishes online diagnosis, which monitors component status and stores trouble codes, from offline diagnosis, which reads ECU information through external diagnostic facilities. Comparing them can help separate internal fault monitoring from what an external tester can retrieve.
Which CAN IDs and baud rate should you expect?
Do not treat example CAN settings as AUTOSAR-wide defaults. Infineon’s current DRIVECORE diagnostic-stack documentation gives a CAN default baud rate of 500 kbps and, as project configuration examples, physical request ID 0x703, functional request ID 0x7DF, and physical response ID 0x70A. These are example values for that documented configuration, not universal IDs or a required bitrate for other ECUs. Compare the ECU configuration with the tester setup and vehicle network definition before diagnosing an ID or bitrate mismatch.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Rank #3
- MPN: IPEH-002021
- USB 1.1 , 2.0 , and 3.0 compatible
- Supports baud rates up to 1M
- 9-pin Male SUB-D. Storage Temperature-( -40°C) to +100°C
- Supports all interrupt and port addresses configurations of the USB interface
What version and standards context matters?
CanTp is the transport layer in the described diagnostic path, and Infineon identifies ISO 15765-2 for its implementation. The cited Dcm description references ISO 14229-1, ISO 15031-5, ISO 15765-4, and SAE J1979. Use the standards and module behavior that apply to the ECU’s actual AUTOSAR release and configuration.
EE Times’ explanatory article dates to 2010 and includes statements tied to AUTOSAR 3.1. Those historical version-specific comments should not be read as a description of feature support in current AUTOSAR releases. For present-day layer responsibilities, the AUTOSAR R24-11 layered-architecture document and current Renesas and Infineon documentation are the more relevant references identified here.
Quick Recap
Best Value
- CUSTOM-DESIGNED FOR USE WITH FORSCAN: Works with all FORScan compatible vehicles and is recommended by the FORScan Team
- DEALERSHIP-LEVEL DIAGNOSTICS: OBDLink EX supports all Ford protocols, modules, and advanced features of FORScan
- ELECTRONIC SWITCH allows FORScan to access all CAN buses simultaneously and enables advanced functions not possible with “toggle switch” adapters
- MAXIMUM THROUGHPUT -- up to 20 times faster than “toggle switch” adapters
- ROCK-SOLID CONNECTION avoids data corruption and dropped packets
Rank #4

- 【Find OBD2 Connection Problems Faster】 When a scan tool won’t connect or communication becomes unstable, this OBD2 breakout box helps you quickly check the vehicle’s communication, power and ground circuits. Easily narrow down whether the issue may come from the OBD port, vehicle wiring, ECU communication or connected diagnostic equipment—less guesswork, more efficient troubleshooting.
- 【See Power, Ground & Communication at a Glance】 No need to start every diagnosis by probing individual circuits. Color-coded LEDs give you an instant visual check of power, ground and communication activity, while the built-in voltage display lets you verify OBD port voltage in real time. Spot abnormal conditions quickly before moving on to deeper testing.
- 【Go Beyond What a Scan Tool Can Show】 A scan tool tells you when communication fails—this breakout box gives you direct access to all 16 OBDII circuits to investigate why. Check individual connections and monitor circuit activity without repeatedly probing the vehicle’s OBD connector, making electrical and CAN Bus troubleshooting easier and more organized.
- 【Ready for Multimeter & Oscilloscope Testing】 Need more than an LED indication? Standard 4mm banana sockets let you connect a compatible multimeter or oscilloscope for voltage measurement and signal analysis. Move smoothly from a quick visual check to deeper electrical diagnosis without changing your entire test setup.
- 【50.4" Extended Cable – More Room to Work】 Stop working around a breakout box hanging underneath the dashboard. The 128cm / 50.4" extension cable gives you enough reach to move the tester away from the cramped footwell and place it where the display and LEDs are easier to see—especially useful when working with additional diagnostic equipment.
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

