
Choose an RTOS for a constrained device that must respond predictably, use little power, and run a focused firmware image. Choose embedded Linux when the product needs an application processor, richer user-space software, storage, or a broad set of networking and application services. PREEMPT_RT can make Linux substantially more preemptible, but it does not guarantee a deadline on every hardware and workload combination. The right comparison is therefore about the whole device: processor, memory, peripherals, software, power budget, and the response time the product must meet.
What does “real-time” mean for an IoT device?
Real-time does not simply mean “fast.” A real-time system must produce a correct result within a required time bound. If a motor-control command arrives after its deadline, the answer can be logically correct and still be a system failure. The deadline and the consequence of missing it determine how strict the design must be.

That is why average speed is not enough to choose an operating system. A design review should consider worst-case response time and jitter—the variation in when a task runs—as well as whether the required bound can be measured and maintained on the actual device. Canonical’s 2024 discussion of Linux real-time behavior emphasizes that latency can enter at every level, from hardware through the kernel to the application.
RTOS vs embedded Linux: the practical differences
| Design concern | RTOS, such as Zephyr or FreeRTOS | Embedded Linux, with or without PREEMPT_RT |
|---|---|---|
| Timing | A small, priority-driven system is often easier to analyze and bound. Worst-case latency still needs validation on the target hardware. | PREEMPT_RT improves preemption and interrupt handling, but shared resources and workload behavior can still contribute to jitter. |
| Processor and memory | Often suited to MCU-class hardware and constrained RAM and flash. Zephyr supports compile-time resource configuration and a combined application-and-kernel image. | Typically paired with an application processor and needs more memory and storage for boot firmware and the broader software stack. |
| Software model | Application and kernel are commonly built into one image, with fewer boundaries between application code and the operating system. | Provides a richer user space with processes, filesystems, package ecosystems, and mature networking and storage services. |
| Hardware enablement | Depends on the selected RTOS port, board support, drivers, and vendor SDK. Zephyr offers a consistent driver model across a range of architectures. | Linux has a broad driver ecosystem, but the chosen board still needs suitable board support, device-tree configuration, kernel configuration, and—if required—real-time tuning. |
| Power and startup | A small image and direct hardware control can support low power and quick startup. | More services and memory can raise power use and boot cost; the result depends on the product’s actual configuration. |
| Maintenance | Assess the RTOS’s governance, tools, certification needs, vendor support, and long-term maintenance arrangements. | Plan for the kernel and LTS strategy, board-support-package upkeep, security updates, and integration of real-time changes. |
These are architectural tendencies, not performance guarantees. There is no universal RTOS-versus-Linux latency, power, or cost figure: the operating system, hardware, drivers, workload, and configuration all matter.
Recommended Free Tools
#1 Best Overall

- Dual-Core Performance Up to 240 MHz: Run sensor processing, wireless communication, automation logic and connected-device tasks on a 32-bit dual-core ESP32 platform designed for responsive embedded and IoT projects
- Built-in Wi-Fi and Bluetooth 4.2: Connect to 2.4 GHz Wi-Fi networks or use Bluetooth Classic and BLE for wireless sensors, smart devices, remote controls, home automation and other connected projects
- Flexible Power-Saving Modes: ESP32 power-management features support dynamic clock scaling and low-power operating modes, helping developers reduce energy use in compatible sensing, monitoring and connected-device applications, suitable for battery-powered Internet of Things (IoT) devices.
- USB-C Programming with CP2102: Connect through USB-C for power, sketch uploads and serial monitoring, while GPIO, UART, SPI and I2C interfaces support sensors, displays, motor drivers and other modules (USB-C cable not included)
- Over-the-Air Update Support: Configure OTA functionality through a compatible ESP-32 software framework to update deployed firmware over Wi-Fi without reconnecting the board by USB for every revision
What PREEMPT_RT changes—and what it cannot promise
PREEMPT_RT changes parts of the Linux kernel’s execution model to make more work preemptible or runnable in thread context. The Linux kernel’s real-time documentation describes threaded interrupts, sleeping locks, changes to timer context, and restrictions on memory allocation in non-preemptible sections. It states: “All interrupts are forced-threaded in a PREEMPT_RT system.” Canonical’s 25 January 2024 article also describes priority inheritance and changed locking primitives as part of making Linux more preemptible.
Those changes can help a high-priority task run sooner, but they do not isolate it from every delay. Hardware contention, memory and cache use, networking, drivers, and application workload can affect the timing of the complete system. Canonical puts the qualification plainly: “Every level can be a source of latency, from the hardware to the kernel and the application.” Treat PREEMPT_RT as a way to improve Linux’s real-time behavior, not as a substitute for defining deadlines and testing the complete device.
How to validate a real-time requirement
- Write down the required response bound, acceptable jitter, and the consequence of a missed deadline.
- Build the timing-critical workload on production-representative hardware with the intended drivers, peripherals, and software configuration.
- Measure under the combinations of load that matter to the product, including relevant networking, storage, and application activity.
- Confirm that recovery and failure behavior are acceptable when a deadline is missed or a component stops responding.
A benchmark on a different board or a lightly loaded development system cannot establish the worst-case behavior of the shipped product.
Rank #2

- Certified & Future-Ready: Espressif-certified ESP32-WROOM-32E ensures full hardware compatibility and lifetime firmware support. Upgraded 8MB Flash handles IoT data and OTA updates.
- Dual-Core Speed: 240MHz dual-core processor runs Wi-Fi/BLE and sensors 2x faster. 38 GPIO pins (10 RTC) support SPI/I2C/UART for LCDs, motors, and industrial sensors.
- Plug & Play Dev: USB-C driver pre-installed: upload code instantly on Windows/Mac/Linux. Works with Arduino IDE, MicroPython, and Espressif IDF.
- All-Environment Ready: Run Wi-Fi smart switches (Home Assistant) and BLE tracking on one board. Industrial-grade stability (-40°C~85°C) for outdoor/automated systems.
- Advantages: The ESP32 development board offers high performance, low power consumption, and rich wireless connectivity, making it suitable for developers of all levels, especially beginners.
When should you choose an RTOS?
An RTOS is a strong starting point when the device is fundamentally a controller or sensor: it samples inputs, manages a radio or bus, actuates hardware, and must operate within tight resource and power budgets. It is especially attractive when the application can fit into a bounded firmware image and predictable task scheduling matters more than a general-purpose user space.
Crashes, No Sound, or Screen Glitches?
Random freezes, missing sound and display glitches usually trace back to one bad driver. Find and replace yours safely.Free scan · under a minutePC Slower Than It Used to Be?
A free scan shows the junk files, broken settings and background clutter dragging Windows down - then fixes them in one click.Free scan · Windows 10 & 11Zephyr’s official documentation describes it as a small-footprint kernel for resource-constrained embedded systems, including sensors, wearables, controllers, watches, and wireless IoT devices. It supports configurable cooperative and preemptive scheduling, power management, drivers, devicetree, networking, Bluetooth LE, filesystems, and compile-time resource definition. Its documented architecture support includes ARM Cortex-M and Cortex-A/R, RISC-V, x86, ARC, MIPS, and Xtensa, among others; actual device support depends on the board, drivers, and maintained port available to the project.
Zephyr can compile the application and kernel into the same binary artifact, typically sharing an address space. Its POSIX subset can help port some Linux-oriented applications and libraries, but it is not a promise that arbitrary Linux software will run unchanged on a small MCU.
Rank #3
Choose an RTOS when these constraints dominate
- Battery life, low sleep current, or fast startup is central to the product.
- The hardware is an MCU with limited RAM and flash, and the required features fit a firmware-scale software model.
- Control, sensing, or actuation has a deadline that must be analyzed directly.
- The device does not need the processes, package ecosystem, filesystem services, or application stack expected from Linux.
When is embedded Linux the better fit?
Embedded Linux is usually the better fit when the product behaves more like a compact computer than a single-purpose controller. Gateways, cameras, HMI devices, and edge-analytics products may need several applications, extensive connectivity, storage, codecs, containers, or mature user-space services. An application processor and the extra memory and storage for Linux can be a reasonable trade for that flexibility.
Linux’s ecosystem can reduce the need to build common software services from scratch, but it does not remove integration work. The chosen board needs suitable drivers and board support; device-tree and kernel configuration must match the hardware. If timing is important, the system also needs deliberate configuration and measurement rather than an assumption that Linux’s general-purpose behavior is sufficiently predictable.
Quick wins for a faster PC:
Scan for outdated or missing drivers - takes under a minuteDriver Scan →Repair Windows errors before they cause bigger problemsFix Now →Linux is probably too heavy when
- The device has a small MCU-scale memory and storage budget, and adding boot firmware and a larger software stack is not justified by its features.
- The product needs only a focused set of sensing, control, and communication functions.
- Power use or startup requirements are incompatible with the proposed Linux configuration.
- The team cannot maintain the board support, kernel configuration, and security updates required for the product’s service life.
“Too heavy” is a product decision, not a fixed RAM threshold. The workload, board, enabled services, and maintenance plan matter as much as the operating-system label.
Rank #4

- 2.4GHz Dual Mode WiFi + Bluetooth Development Board
- Support LWIP protocol, Freertos
- SupportThree Modes: AP, STA, and AP+STA
- Ultra-Low power consumption, Compatible with Arduino IDE
- ESP32 is a safe, reliable, and scalable to a variety of applications
Which hardware should you use for each option?
MCU plus RTOS
Start with an MCU and RTOS for low-power sensing, battery-operated endpoints, deterministic control, and fixed-purpose devices that fit a bounded firmware image. Check the exact board’s RTOS support, peripheral drivers, RAM and flash capacity, radio support, and power modes; architecture support alone does not establish that a particular board is ready for the product.
Application processor plus embedded Linux
Start with an application processor and Linux for a gateway, camera, HMI, or edge device that needs richer connectivity, filesystems, analytics, or a broad user-space software stack. Include the memory and storage needed by the complete product configuration, not just the kernel, and confirm who will maintain the board-support package and updates.
Split architecture for mixed workloads
Some products can give Linux responsibility for networking, user interface, and analytics while a second MCU or dedicated core handles hard real-time control. This can separate application complexity from time-critical work, but it introduces an inter-processor boundary. Measure communication latency and define what happens if either side resets, stalls, or loses the link; a split architecture is only as robust as those interfaces and failure paths.
Free tools Windows power users keep installed
One-click scans. No signup required.
Best Value
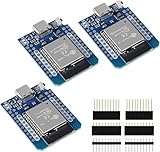
- D1 Mini NodeMCU Type-C ESP32 WLAN WiFi Bluetooth IoT Development Board 5V Compatible for Arduino
- Designed with ultra-low power technology, it offers the full range of performance and features of the ESP32 chip. The pin arrangement provides compatibility with the modules developed for the D1 Mini ESP8266 while also offering fast WLAN, enhanced GPIO, Bluetooth functionality, and with its higher performance, a wider range of applications.
- 100% compatible with Arudino IDE, Lua and Micropython, it shows robustness, versatility, and reliability in a wide variety of applications and power scenarios.
- All I/O pins have interrupt, PWM, I2C and one-wire capability, except the pin DO.
- Designed with ultra-low power technology, it offers the full range of performance and features of the ESP32 chip. The pin arrangement provides compatibility with the modules developed for the D1 Mini ESP8266 while also offering fast WLAN, enhanced GPIO, Bluetooth functionality, and with its higher performance, a wider range of applications.
A 2026 preprint reports evaluating a 250 Hz control loop using PREEMPT_RT Linux on a Raspberry Pi 5 and identifies shared hardware resources as a source of jitter. That is a useful example of why even a concrete board-and-loop result is evidence for evaluating a configuration, not a performance guarantee for other workloads or devices.
How much do ecosystem and memory figures tell you?
A Zephyr Project summary of Linux Foundation Research published in 2026 reports that 30% of surveyed organizations standardize on one RTOS, 29% keep a small RTOS portfolio, and 20% evaluate RTOS platforms per project. The same summary says the largest surveyed share targeted embedded products with 128 KB to 512 KB of RAM. These are survey findings about respondents and products, not minimum specifications for Zephyr, Linux, or any individual device.
The figures are a reminder that teams make different choices based on product needs and organizational capability. They do not answer whether a particular Linux image will fit, whether a given RTOS has the needed driver, or which system will meet a deadline. Resolve those questions against the specific hardware and software configuration.
Questions to settle before committing to an OS
- Timing: What is the worst-case deadline, what jitter is acceptable, and what happens if the deadline is missed?
- Features: Which peripherals, buses, radios, filesystems, codecs, containers, or user-space services are required?
- Resources: What are the RAM, flash or storage, CPU, power, and boot-time budgets?
- Platform: Does the hardware have an MMU or MPU where needed, and is there maintained board support for the selected OS?
- Product obligations: What security model, update mechanism, certification, and support lifetime must the product meet?
- Verification: Can the team measure worst-case latency, jitter, boot time, power, and recovery behavior on representative hardware?
- Ownership: Who will maintain the OS port, drivers, security patches, toolchain, and board support over the product’s service life?
How to make the decision
First set the deadline and resource budgets, then list the software and hardware features the product actually needs. If a focused MCU firmware image can meet those requirements, an RTOS is usually the more natural fit. If the product depends on a rich application environment, storage, or broad user-space software, embedded Linux is usually the more natural fit. If Linux must also meet a tight timing bound, evaluate PREEMPT_RT on the target configuration; if critical control needs a firmer boundary, consider assigning it to a separate MCU or core. In every case, validate timing, power, startup, and failure behavior on the hardware and workload the product will ship with.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

