
SSD stands for Single Shot MultiBox Detector. It detects objects in one pass through a neural network: the model predicts both class scores and adjustments to candidate boxes, without first generating a separate set of region proposals. Its multiple-resolution feature maps help it make predictions for objects at different scales.
What “single shot” means
Earlier detection pipelines could first propose image regions and then process those regions to classify and refine them. SSD combines those tasks in one network pass, avoiding a separate proposal stage and the associated per-proposal feature resampling. “Single shot” describes this detection approach; it does not mean the model returns only one box.
The original paper describes SSD as discretizing bounding-box outputs into default boxes with different scales and aspect ratios at each feature-map location. Each box receives predictions that help determine what is in the box and how its coordinates should change.
How SSD turns feature maps into detections
1. It builds feature maps at several resolutions
A feature map is a grid of learned image information. SSD makes predictions from multiple feature maps at different resolutions. This gives the detector opportunities to find objects at different scales rather than relying on one grid alone.
Quick wins for a faster PC:
Repair Windows errors before they cause bigger problemsFix Now →Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →Clear out junk files and repair common Windows errorsFree Scan →#1 Best Overall

- Robot vision made easy - press the button to teach Pixy2 an object.
- New with Pixy2: line following mode and integrated LED light source!
- Simplify your programming - receive just the objects you're interested in.
- Use whatever controller you want - includes software libraries for Arduino, Raspberry Pi, and BeagleBone Black.
- Configuration utility runs on Windows, MacOS and Linux
2. It places default boxes at feature-map locations
At each location, SSD uses a set of default boxes, also called box priors. Their selected scales and aspect ratios provide different starting shapes and sizes. They are starting guesses, not finished detections.
3. It predicts class scores and box offsets
For each default box, prediction heads output class scores and coordinate offsets. The scores indicate which object category the box may contain; the offsets adjust the box’s position and dimensions. The final predictions therefore come from both classification and box refinement, not simply choosing one pre-drawn box.
How SSD is trained in the TorchVision implementation
In the TorchVision implementation described by its tutorial, training matches ground-truth boxes to default boxes and then calculates classification and box-regression losses. That tutorial describes smooth L1 loss for box regression and cross-entropy loss for classification, with hard-negative sampling. These are details of that implementation, not requirements that define every SSD variant.
Rank #2

- Hidden Camera,Mini Camera
Trying SSD in PyTorch
Choose the model variant before following setup instructions: “SSD” identifies an architecture family, not one fixed backbone or configuration.
The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →- TorchVision’s
ssd300_vgg16documentation lists a builder for an SSD300 model with a VGG-16 backbone. TorchVision labels its detection module beta and warns that backward compatibility is not guaranteed, so check the documentation for the version you use. - PyTorch Hub’s SSD300 example describes a ResNet-50 backbone with six detection heads. It is a distinct implementation configuration, not evidence that the original SSD architecture has only one possible backbone.
Follow the setup and inference code for the selected implementation rather than mixing instructions between the two. The available documentation establishes these model configurations, but does not establish a universal present-day hardware requirement.
What the original SSD speed and accuracy figures show
The 2015 SSD paper reports 72.1% mean average precision (mAP) on the VOC2007 test set for its 300×300-input model, running at 58 frames per second on an NVIDIA Titan X. It also reports 75.1% mAP for a 500×500-input model. These are paper-reported results for the paper’s models, dataset, resolutions, and hardware—not guarantees for current implementations or modern systems.
Rank #3
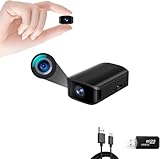
- 【Mini Camera】: This Portable camera is rectangular in shape, with dimensions of 0.7×1.18×1.9 in. It is easy to carry around and place anywhere, allowing you to record continuously for up to 3.5 hours. It also supports record while charging, making it easy to use and ensuring worry-free record.(Video-only surveillance equipment, Via Amazon no audio policy)
- 【1080P Full HD】: This mini camera record high-quality 1920x1080P HD video at 30 fps per second. Additionally, it supports the 【Automatic Night Vision】This Portable cameras is equipped with two high-performance [940nm] infrared night vision lights, enabling clear footage record in dark environments. (without visible light) , allowing you to record with greater peace of mind.
- 【Smart Motion Detection】 Security Camera In Motion Detection Mode, within the visible range of the lens, the camera will intelligently detect and identify moving people or objects on the screen through the AI algorithm and automatically record the video. It can effectively save the memory card's storage. This camera also with the 【Latest Gravity Sensor Technology】 which means that even if you flip it up and down 180°, the video will always be in an upright orientation.
- 【Time Watermark】 function, allowing you to correct the watermark time in videos and enable or disable the watermark. 【Loop Record Function】Ensures continuous monitoring by overwriting old videos with new ones. (Maximum support for 512GB)
- 【Easy Operation】Easily connect to PC via USB port and transfer desired videos without software. - NOTE: Contact us anytime for product inquiries. 【Easy to Use】This Portable size cam is very easy to operate. Just insert a SD card and turn the only button to start and stop working. Anyone can use it easily. (NO SD CARD IS PROVIDED)
Those figures are not enough to rank SSD against current detectors. A meaningful comparison needs the dataset and evaluation metric, input size, hardware, implementation, accuracy, and inference speed. The paper’s comparison with detectors that used a separate proposal stage is historical; it should not be treated as an apples-to-apples comparison with modern detector families.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.What to remember when evaluating SSD
- SSD is a single-stage detector that predicts categories and bounding-box adjustments in one network pass.
- Default boxes provide starting shapes; predicted offsets refine them, while class scores estimate their contents.
- Predictions from feature maps at several resolutions help cover objects at different scales.
- Backbones and setup vary by implementation, so identify the model variant and check its framework compatibility notes.
Sources: Liu et al., “SSD: Single Shot MultiBox Detector”; Google Research record; TorchVision detection tutorial; TorchVision SSD300 VGG-16 documentation; and PyTorch Hub SSD300 example.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

