
An ESP32 can generate the control signals for a slot-car speed controller, but the development board alone is not a motor power supply. A practical build pairs it with a suitably rated power stage, a trigger input, and wiring and power arrangements compatible with the track and cars. The right design depends on whether you want a simple wired analog-track conversion, a configurable handheld controller, or a wireless controller for a digital system.
What an ESP32 does in a slot-car controller
The ESP32 handles control logic: it reads the trigger, applies any throttle mapping or braking behavior, and generates a pulse-width modulation (PWM) signal. The motor current must flow through a separate power stage, such as a motor-driver module selected for the track and car’s electrical requirements.
Espressif’s ESP32-MINI-1 datasheet v1.8, revised August 5, 2026, lists a Motor Control PWM peripheral and specifies a 3.0–3.6 V operating supply for that module. That describes the module, not every development board: a DevKit may include a regulator and other circuitry. Check the documentation for the exact board, and never connect track voltage directly to a bare ESP32 module.
Choose an architecture before choosing parts
| Design | What it is suited to | What to check |
|---|---|---|
| Wired PWM conversion | A straightforward conversion for an analog slot-car setup using a trigger and separate motor driver. | Track and car compatibility; trigger wiring; driver voltage and current ratings; regulated power for the ESP32. |
| Configurable ESP32 handheld controller | A build where adjustable behavior, calibration, profiles, or telemetry are desired. | Whether the project’s hardware, firmware, trigger, and track interface match your setup. |
| Wireless digital controller | A digital slot-car system designed to accept wireless electronic control. | Compatibility with the particular digital track system and its control interface. |
The ESPEED32 project describes itself as “an open-source slot car controller project built around ESP32 hardware for DIY builders who want flexible setup, tuning, flashing, troubleshooting, and day-to-day racing use.” Its overview lists adjustable PWM frequency, throttle curve, anti-spin and brake behavior, magnetic-trigger support and calibration, per-car profiles, telemetry, firmware and storage updates, and browser-based setup tools. These are project-described features, not independently established performance results. See the ESPEED32 project overview.
#1 Best Overall
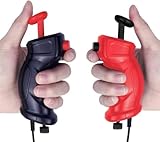
- Traditional Style for Classic Control – Includes 2 retro-inspired slot car remotes (1 red, 1 black) with a timeless design for players who prefer a simple, familiar grip.
- Manual Speed Adjustment via Bottom Dial – Fine-tune your racing speed using the rotating adjustment knob on the bottom of each controller for smooth, tailored performance.
- Perfectly Compatible with GWOUD 1:64 HO Track Sets – Plug-and-play with all GWOUD 1:64 HO scale electric race tracks. Ensures seamless replacement or upgrade.
- Ideal for Replacement or Preference – Designed for racers who prefer traditional over the included steering wheel controllers or need backup units for multiplayer racing.
- Lightweight & Durable for Long Play Sessions – Ergonomic ABS construction provides comfort and endurance for kids and adults during extended races.
A Tampere University thesis listing describes a wireless electronic controller for digital slot cars that uses PWM for acceleration and braking and discusses selectable control modes. The available listing supports that broad description, but not detailed claims about the design’s implementation. See the Tampere University repository listing.
What a documented basic build requires
One public project describes a basic PWM Scalextric controller built around an ESP32 DevKit and a BTS 7960 dual H-bridge motor controller. Its stated prerequisites are:
Rank #2

- Small scale for small drivers
- Designed to be used with 2 lanes at a time
- 1: 43 scale
- An ESP-32 DevKit board.
- A BTS 7960 dual H-bridge motor-controller module.
- A slot-car controller handle to convert.
- Wiring appropriate to the project.
The example says its board needs an additional regulator to convert “10+V from the track” to 5 V, and that USB can power the board during testing. Those are details of that particular project, not general specifications for all tracks, ESP32 boards, or motor drivers. Check the source project’s circuit and the specifications for your actual components before reproducing its arrangement: ESP32 Scalextric controller project.
Select and calibrate the trigger
The same example identifies three possible trigger approaches: a rotary potentiometer, a resistor board, or a modified barrel-resistor controller. It describes modifying an old resistor controller, but does not establish a universal wiring scheme. The input you choose must suit the controller design and be calibrated so the firmware interprets the trigger’s range correctly.
Quick wins for a faster PC:
Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →Repair Windows errors before they cause bigger problemsFix Now →Rank #3

- Powerful Motor Integration: Onboard 3A motor driver directly controls (4 Servo + 4 Encoder Motors) or (4 Servo + 4 DC Motors). Docs: github.com/nulllaborg/maker-esp32-pro
- ESP32 IoT Core: Official ESP32-WROOM-32E module. Features a dual-core module with built-in 2.4GHz WiFi and Bluetooth (BLE) for powerful, low-latency wireless communication and IoT applications.
- Wide Voltage: Supports 6V-16V wide voltage input via DC port.
- Instant Expansion: Includes 5x I2C ports, 1x SPI ports, 13x GPIOs, allowing you to add sensors, OLED displays with ease.
- Application: Essential for robotics; no external shields required. Ideal for DIY your robots, smart cars.
- Rotary potentiometer: provides a variable input; confirm its electrical range and mechanical fit for the handle and firmware.
- Resistor board: may suit a design intended to read discrete or resistor-based trigger positions; verify the project’s expected input circuit.
- Modified resistor controller: reuses an existing handle, but the modification must match the chosen electronics and preserve safe, reliable connections.
Check power, driver ratings, and compatibility
Before wiring or buying parts, match the complete system rather than assuming that a module named in another build will work for yours. The available project examples do not establish a universal track voltage, motor current, or compatible driver rating.
- Track and cars: determine whether the setup is analog or digital and confirm that the proposed controller interface is supported.
- Motor power stage: check the driver’s voltage and current ratings against the intended track and cars, along with its protection and cooling requirements in the manufacturer’s documentation.
- ESP32 supply: provide the exact board or module with its specified regulated supply. The ESP32-MINI-1 module’s documented 3.0–3.6 V range is not permission to apply track power to it.
- Trigger and firmware: confirm that the input type and calibration procedure match the controller software.
- Behavior: establish whether you need only throttle control or also a configurable throttle curve, anti-spin behavior, braking, profiles, or telemetry.
Build and test in a controlled sequence
- Identify the system: record the track type, car requirements, controller interface, and the voltage and current demands that the power stage must handle.
- Choose the controller design: select a wired conversion, configurable handheld project, or wireless digital approach that is intended for that system.
- Verify every component: check the exact ESP32 board or module, motor driver, regulator, trigger, wiring, and protection against their documentation before connecting track power.
- Set up the trigger input: wire the chosen potentiometer or other supported trigger as the project specifies, then perform its calibration procedure.
- Test the logic supply separately: where the project supports it, USB can be used to power the board for testing; do not treat that as a substitute for verifying the motor-power circuit.
- Test the assembled controller cautiously: follow the project’s operating and safety instructions, check for unexpected heating or behavior, and stop if the driver, wiring, or supply falls outside its documented limits.
Which approach should you use?
For a basic wired analog conversion, the documented ESP32 DevKit and BTS 7960 example gives a concrete starting point, but its specific power and wiring notes must be checked against your components. Choose a configurable project such as ESPEED32 if its listed features and supported trigger align with the build you want. A wireless digital design is a separate compatibility problem: PWM control concepts alone do not make a controller compatible with a particular digital track system.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

