
iTechGuides is reader-supported. When you buy through links on our site, we may earn an affiliate commission. As an Amazon Associate I earn from qualifying purchases. Learn more
You can use a FlySky FS-i6 to send radio commands to an Arduino-based RC-car modification, but the transmitter does not connect directly to the Arduino. The signal path is FS-i6 transmitter → compatible receiver → Arduino input → suitable steering and motor-control hardware. The exact wiring depends on your receiver’s output mode, Arduino model, and the car’s existing servo, motor, and speed controller; identify those before building a pin-by-pin circuit.
What you need to identify before wiring
The FS-i6 is a six-channel, 2.4 GHz AFHDS 2A transmitter. FlySky lists its data interface as PS/2 (PPM), but the receiver is the part that provides outputs for your Arduino to read. The FS-iA6B is one compatible receiver option; its documented outputs include PWM, PPM, i-BUS, and S.BUS. Check the label on your actual receiver and consult its documentation before choosing a connection method. FlySky FS-i6 specifications and the FlySky Europe FS-i6X catalog describe the transmitter and receiver options; catalog specifications may change.
- Receiver: Confirm its exact model and supported output ports. A transmitter is not a receiver, and not every receiver provides the same interfaces.
- Arduino: Confirm the board and its logic-voltage limits. Choose an input approach that is electrically compatible with the receiver’s signal.
- Car electronics: Identify whether the traction motor is brushed or brushless, what ESC or motor driver it uses, how the steering servo is powered, and how the battery and any BEC are arranged.
- Protocol: Confirm the receiver and transmitter use compatible radio protocols. FlySky says AFHDS, AFHDS 2A, and AFHDS 3 are not mutually compatible.
Without those details, a specific wiring diagram, power plan, or motor-control part recommendation would be guesswork.
Choose a receiver output the Arduino can decode
There are four documented output choices on the FS-iA6B, but they are not interchangeable. Select one supported by both your receiver configuration and the way your Arduino project will read signals.
#1 Best Overall

- 4) The system is built using highly sensitive low power consumption components, maintaining high receiver sensitivity, while consuming as little as one tenth the power of a standard FM system, dramatically extending battery life.
- 2)Reliable, interference free 2.4GHz AFHDS 2A signal operation.
- 3).Associated with a High Sensitivity Receiver, This Radio System Guarantees a Jamming Free Long Range Radio Transmission Each Transmitter Has a Unique Id, When Binding with a Receiver, The Receiver Saves That Unique ID and Can Accepts Only Data From The Unique Transmitter.
- 4)6CH operation. Use only 4 * AA batteries for transmitter.(Not included)
- 5)Quick and extremely stable in performance.
| Receiver output | Signal arrangement | What to account for |
|---|---|---|
| PWM | Separate output for each channel | Read each channel you need from its own receiver output. This is relatively easy to inspect one channel at a time, but involves separate signal connections. |
| PPM | Multiple channels combined on one signal | The Arduino needs a PPM decoder. Confirm the receiver has a PPM or PPM/CH1 output; FlySky says to set the radio to PPM when using a PPM-capable interface. |
| i-BUS | Serial-style receiver output | Use an appropriate i-BUS decoding method. Do not wire it as though it were a PPM signal. |
| S.BUS | Serial-style receiver output | Use an appropriate S.BUS decoding method. It is distinct from both PPM and i-BUS. |
The receiver and radio settings determine which interfaces are usable. FlySky’s support FAQ discusses receiver compatibility, PPM selection, and receiver supply voltage. These sources establish the available signal types, but do not validate a particular Arduino library, sketch, pin mapping, or signal-level conversion for every board and receiver pairing.
Plan the power and motor-control paths separately
The receiver’s radio signal is an input to the Arduino; it is not a source of traction-motor power. Never connect a car’s drive motor directly to an Arduino GPIO. Use the vehicle’s suitable ESC or motor driver, selected for the motor type and its voltage and current requirements. The car’s existing electronics may already provide the necessary steering and motor control, but that cannot be assumed without identifying them.
Rank #2

- Please note: Flysky FS-i6X is default 6CH with FS-iA6B Receiver. If you have 10 channels receiver FS-iA10B, that you can open to 10 channels.
- Bidirectional Communication --- Capable of sending and receiving data, each transmitter is capable of receiving data from temperature, altitude and many other types of sensors, servo calibration and i-BUS Support
- Multi-channel Hopping Frequency --- This system bandwidth ranges from 2.408GHz to 2.475GHz. This is divided in 135 channels. Each transmitter hops between 16 channels (32 for Japanese and Korean version) in order to reduce interference from other transmitters.
- Omni-directional Gain Antenna --- The high efficiency Omni-directional high gain antenna cuts down on interference, while using less power and maintaining a strong reliable connection
- Low Power Consumption --- The system is built using highly sensitive low power consumption components, maintaining high receiver sensitivity, while consuming as little as one tenth the power of a standard FM system, dramatically extending battery life.
- Receiver supply: Use the voltage range printed on the receiver. Do not assume an Arduino pin can power it; check the Arduino’s limits and the receiver’s requirements.
- Grounding: Determine how the battery, ESC or driver, receiver, and Arduino are powered before joining grounds. Avoid connecting power rails or grounds based on an assumed arrangement.
- Signal levels: Check the receiver output and Arduino input electrical limits before connecting a signal. A board-specific interface or level conversion may be needed.
- Steering: Establish whether the existing steering servo remains connected to the receiver, is controlled through the Arduino, or is replaced. The correct arrangement depends on the project’s control design.
FlySky’s operating guidance says to mount the receiver away from motors and metal parts and to keep the model in sight. Its FS-i6/FS-iA6 operating manual also warns: “Never grip the transmitter antenna during operation.” See the FS-i6/FS-iA6 operating manual.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Build and test in a controlled sequence
- Label the hardware: Record the receiver model, output mode, Arduino board, battery arrangement, steering servo, motor type, and ESC or driver. Find the receiver’s printed supply range and each board’s signal limits.
- Bind and configure: Bind the FS-i6 to the compatible receiver using their manuals. Set up the receiver output mode you intend to read; for PPM, select PPM in the radio setup where required and verify the receiver’s PPM-capable output.
- Connect the receiver input path: Wire only the selected signal interface and a properly planned reference ground and supply. Follow the receiver and Arduino documentation for the actual pins; do not infer a pin map from a different model.
- Confirm channel readings: With the drive wheels lifted, verify that the Arduino sees neutral and changing commands for the intended steering and throttle channels before enabling the motor.
- Check direction and failsafe: Confirm steering moves the intended way, throttle is neutral when expected, the usable throttle range is appropriate, and loss of radio signal produces a safe response. Adjust the transmitter, code, or hardware only after identifying which part causes the behavior.
- Test operation and distance: Keep the car in a controlled area, the model in sight, and the wheels clear during early motor tests. Check steering, motor operation, and control distance before driving, as the manual recommends.
Why a generic Arduino wiring recipe may not fit
A secondary Arduino Nano guide surfaced as a reference, but it identifies itself as version 0.8.0, says its references were checked on 5 September 2026, and explicitly says the receiver hookup is untested. Its receiver wiring should therefore not be treated as a validated build. Even a tested example would only apply if your receiver interface, Arduino, and car electronics matched its hardware.
Rank #3
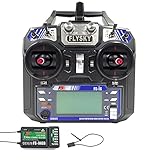
- This radio system uses low power electronic components and sensitive receiver chip. The RF modulation uses intermittent signal thus reducing even more power consumption
- 2)Reliable, interference free 2.4GHz AFHDS 2A signal operation.
- This radio system uses a high gain and high quality multi directional antenna, it covers the whole frequency band. Associated with a high sensitivity receiver, this radio system guarantees a jamming free long range radio transmission.
- 4).Associated with a High Sensitivity Receiver, This Radio System Guarantees a Jamming Free Long Range Radio Transmission Each Transmitter Has a Unique Id, When Binding with a Receiver, The Receiver Saves That Unique ID and Can Accepts Only Data From The Unique Transmitter.
- Works in the frequency range of 2.405 to 2.475GHz.This band has been divided into 142 independent channels, each radio system uses 16 different channels and 160 different types of hopping algorith
For a reliable schematic, first establish the receiver model and output mode, Arduino variant and logic voltage, motor and ESC or driver specifications, steering arrangement, and battery/BEC power layout. Those details determine the actual wiring and any required interface circuitry.
Quick Recap
Best Value
- Offering superior protection against interference while maintaining lower power consumption and high reliable receiver senstivity.
- Bidirectional Communication Capable of sending and receiving data, each transmitter is capable of receiving data from temperature, altitude and many other types of sensors, servo calibration and i-BUS Support.
- Each transmitter and receiver has it's own unique ID. Once the transmitter and receiver have been paired, they will only communicate with each other, preventing other systems accidentally connecting to or interfering with the systems operation.
- The high efficiency Omni-directional high gain antenna cuts down o interference, while using less power and maintaining a strong reliable connection.
- The system is built using highly sensitive low power consumption components, maintaining high receiver sensitivity, while consuming as little as one tenth the power of a standard FM system, dramatically extending battery life.
Rank #4

- Quick response. Applicable to Fixed wing/Glider/Helicopter. It can also be compatible with rc Car rc Boat, even if these icons are not in the menu.Attach a DIY label to it.
- Reliable and highly anti-interference 2.4GHz AFHDS 2A system. Remote control distance of 500 meters in the air.
- The FS-i6 transmitter is compatible with the AFHDS 2A series receivers FS-iA6, FS-iA6B, FS-iA10B, FS-X6B, FS-A8S (receivers not included in the packaging can be purchased separately), suitable for different DIY RC aircraft, Boat, etc.
- Unique ID Recgnition System --- Each transmitter and receiver has it's own unique ID. Once the transmitter and receiver have been paired, they will only communicate with each other, preventing other systems accidentally connecting to or interfering with the systems operation.
- 1 3-stage switch, 3 2-stage switches, 2 knobs. Customizable allocation of the 5th or 6th channel. Owning Aux Channels; Throttle curve; Mix * 3; Elevon and other functions can store 20 sets of model programming data.
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

