
Outdated Drivers Are Slowing You Down
One free scan finds every outdated or missing driver and matches the right update for your exact hardware.Free scan · exact hardware matchPC Slower Than It Used to Be?
A free scan shows the junk files, broken settings and background clutter dragging Windows down - then fixes them in one click.Free scan · Windows 10 & 11Yes—with important limits. The practical route is to install an Ubuntu 24.04 userland inside Termux with proot-distro, then install ROS 2 Jazzy in that Ubuntu environment. This can work well for learning ROS 2, running lightweight nodes, and testing network communication. It is not native Android support, and it is not a dependable substitute for an Ubuntu robotics computer when you need graphics, device drivers, or real-time control.
What you are actually installing
The setup is layered: Android runs Termux; Termux runs an Ubuntu userland through PRoot; ROS 2 runs inside Ubuntu.
Android
└── Termux
    └── Ubuntu 24.04 through proot-distro
        └── ROS 2 Jazzy
This distinction matters. Native Termux packages are built for Android’s Bionic environment, not Ubuntu’s usual glibc-based system and filesystem layout. Standard ROS packages are therefore not normally installed with Termux’s pkg command. Install them inside the Ubuntu userland instead. Termux explains its execution environment and filesystem differences in its execution environment documentation and filesystem layout guide.
PRoot supplies a Linux-style userland without root access, but it does not replace Android’s kernel with an Ubuntu kernel. That is why software expecting conventional Linux privileges, kernel features, or direct device access may fail. See the proot-distro project.
#1 Best Overall

- 【Strong Adsorption】The inspiration of the silicone phone suction case comes from the adhesive force of the octopus. Each suction cup phone mount is 3.15 inches long and 2.17 inches wide, with 24 independent suction cups providing a stronger and more stable suction force, so you don't have to worry about your phone falling during use.
- 【Back of Phone Suction Grip】Remove the adhesive film on the phone suction cup and stick it on the phone case. You can then fix the phone on any smooth surface, which is very convenient. (The phone suction cup cannot be removed and reused after being attached to the phone case. It is recommended to attach it to a regular phone case, not a valuable one.)
- 【Widely Used】Our non-slip silicone phone sticky grip mount attaches to almost any flat phone case and make it compatible with common mobile phones such as iPhone and Android.You can shoot, watch videos or video calls in the kitchen, gym, dance studio, bathroom and other places.
- 【Capture the Wonderful Picture】Whether you are a TikTok creator or just like to share videos and photos, this phone suction cup can help you hands-free capture wonderful videos and photos for sharing with friends.
- 【Note】You can fix the phone suction cup on a smooth surface such as a mirror or glass. If necessary, wipe the suction cup with a damp cloth to obtain stronger suction. Before releasing your hand, make sure the phone is firmly fixed. (Not applicable to rough walls, wooden surfaces, and other uneven surfaces)
What is realistic on a phone?
| Task | What to expect |
|---|---|
| ROS 2 command-line tools and basic nodes | Reasonable for learning and experimentation on a suitable 64-bit device. |
| Python or C++ nodes and small workspaces | Possible, though compilation may be slow and dependencies can expose PRoot or architecture limitations. |
| ROS 2 networking with a PC or robot | Useful when both devices can communicate on the network and DDS discovery is permitted. |
| RViz and other graphical tools | May be possible through Termux:X11, but display forwarding does not guarantee working 3D acceleration. |
| Gazebo and substantial simulation | Usually a poor fit because of resource demands, graphics compatibility, and PRoot limitations. |
| USB serial, cameras, LiDAR, CAN, GPIO, or robot drivers | Unreliable without device-specific Android access and permissions; installing ROS does not provide Linux device drivers. |
| Real-time motor control | Not a dependable use case for Android and PRoot. |
ROS 1 is a legacy path with old mainstream Ubuntu targets, so this guide focuses on ROS 2. Jazzy is the sensible default for an Ubuntu 24.04 setup; Kilted is another option for readers who specifically need that release, but the Android/Termux arrangement remains unofficial. ROS identifies its supported platforms and releases in its getting-started overview. Current binary package support is for selected Linux platforms, not Android or Termux, as the ROS 2 installation documentation makes clear.
Check your device and Termux installation
- Architecture: Prefer 64-bit ARM. In Termux, run
uname -m;aarch64is the expected result. A 32-bit ARM device is a poor candidate for current Ubuntu 24.04 ROS binaries. - Android version: Current Termux app support is for Android 7 or newer. Termux:X11 requires Android 8 or newer.
- Storage and memory: Leave several gigabytes free, especially if you plan to compile packages or install desktop tools. The required space depends on what you install.
- App source: Install Termux and any add-ons from the same signing source. Mixing builds from different sources can cause signature conflicts. Check the Termux app project for current distribution guidance.
- Background operation: Android may suspend or kill Termux processes. Disable battery optimization for Termux if you need a node to run for an extended session; this still does not make the phone suitable for unattended control.
Install Ubuntu 24.04 in Termux
In the Termux host shell, update packages and install the Ubuntu userland:
pkg updatepkg upgradepkg install proot-distroproot-distro install ubuntuproot-distro login ubuntu
Inside Ubuntu, confirm the release and architecture before adding ROS packages:
cat /etc/os-release
dpkg --print-architecture
uname -m
The ROS binary instructions below are for Ubuntu 24.04 (Noble) on a supported 64-bit architecture. If the image is a different Ubuntu release, or reports an unexpected architecture, do not assume the same package installation will work.
Free tools Windows power users keep installed
One-click scans. No signup required.
Most ordinary proot-distro Ubuntu sessions identify the user as root within that userland. Check with id. If it reports root, run apt directly; you do not need to add sudo.
Install ROS 2 Jazzy
The steps follow the official Ubuntu package route, adapted to the Ubuntu userland inside PRoot. Start by installing the prerequisites and setting a UTF-8 locale, which ROS requires:
apt update
apt upgrade -y
apt install -y locales curl software-properties-common
  python3-pip python3-rosdep python3-colcon-common-extensions
  build-essential git
locale-gen en_US en_US.UTF-8
update-locale LANG=en_US.UTF-8 LC_ALL=en_US.UTF-8
export LANG=en_US.UTF-8
Configure the ROS apt repository using its maintained release package:
Rank #2

- SUPERIOR COMFORT — Unlike traditional circular ear buds, the design of EarPods is defined by the geometry of the ear. Which makes them more comfortable for more people than any other ear bud–style headphones.
- HIGH-QUALITY AUDIO — The speakers inside EarPods have been engineered to maximize sound output and minimize sound loss, which means you get high-quality audio.
- BUILT-IN REMOTE — EarPods with USB-C plug also include a built-in remote that lets you adjust the volume, control the playback of music and video, and answer or end calls with a pinch of the cord.
- COMPATIBILITY — Works with all devices that have a USB-C port.
- INTEGRATED MICROPHONE — A built-in microphone precisely captures your voice while you’re on the phone, taking a FaceTime call, or summoning Siri — so you’re always heard loud and clear.
export ROS_APT_SOURCE_VERSION=$(
  curl -s https://api.github.com/repos/ros-infrastructure/ros-apt-source/releases/latest |
  grep -F "tag_name" |
  awk -F" '{print $4}'
)

curl -L -o /tmp/ros2-apt-source.deb
  "https://github.com/ros-infrastructure/ros-apt-source/releases/download/${ROS_APT_SOURCE_VERSION}/ros2-apt-source_${ROS_APT_SOURCE_VERSION}.$(
    . /etc/os-release && echo ${UBUNTU_CODENAME:-${VERSION_CODENAME}}
  )_all.deb"

dpkg -i /tmp/ros2-apt-source.deb
apt update
For a phone, begin with the smaller command-line-oriented installation:
Quick wins for a faster PC:
Clear out junk files and repair common Windows errorsFree Scan →Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →Repair Windows errors before they cause bigger problemsFix Now →apt install -y ros-jazzy-ros-base ros-dev-toolsros-jazzy-ros-base provides core ROS communication libraries, message packages, and command-line tools. The larger desktop variant includes GUI tools such as RViz and demonstrations:
apt install -y ros-jazzy-desktopROS’s Jazzy Ubuntu installation guide covers locale and repository setup; package variants are described in the Jazzy package installation page. A package being available for Ubuntu does not guarantee every dependency will behave under Android’s shared kernel and PRoot.
Initialize rosdep and add ROS to the shell environment:
rosdep init
rosdep update
echo 'source /opt/ros/jazzy/setup.bash' >> ~/.bashrc
source ~/.bashrc
If rosdep init says it is already initialized, run rosdep update instead of repeating initialization.
Recommended Free Tools
Verify the installation
Open two Termux sessions. In the first, enter Ubuntu and start a publisher:
proot-distro login ubuntu
source /opt/ros/jazzy/setup.bash
ros2 run demo_nodes_cpp talker
In the second session, run a listener:
proot-distro login ubuntu
source /opt/ros/jazzy/setup.bash
ros2 run demo_nodes_py listener
The listener should print messages published by the talker. If either demo package is missing, install it inside Ubuntu:
Rank #3

- Secure Hold: Our PopSockets adhesive phone grip gives your cell phone a secure, comfortable hold in hand to help prevent drops while texting, taking photos, or scrolling on the go. Designed to stick firmly to most phone cases and devices.
- Hands-Free Made Easy: Easily turn your PopSocket into a phone stand to prop up your phone anywhere — perfect for watching videos, video calls, or following recipes. A must-have phone holder that keeps your device secure and ready for anything.
- Compatibility: Works with all phones, tablets, and Kindles. Sticks best to smooth, hard plastic cases and may not adhere to silicone or textured cases. Easily swap your PopTop to change up your style — just close the grip, press down, twist 90°, and snap on a new top.
- Black PopSockets: Simple, refined, and endlessly versatile — a timeless essential for any phone.
- PopSockets Ecosystem: Mix and match your favorite PopSockets products — from grips and wallets to cases and mounts — all designed to work together seamlessly.
apt install -y ros-jazzy-demo-nodes-cpp ros-jazzy-demo-nodes-pyUseful checks include:
ros2 doctor
ros2 topic list
ros2 node list
Build a workspace
A small workspace can be created and built with colcon:
mkdir -p ~/ros2_ws/src
cd ~/ros2_ws
colcon build
source install/setup.bash
For a source package, clone its repository into src, install declared dependencies, and build:
cd ~/ros2_ws/src
git clone <package-repository>
cd ..
rosdep install --from-paths src --ignore-src -r -y
colcon build --symlink-install
source install/setup.bash
Replace <package-repository> with the package’s actual Git URL. Builds may take longer under PRoot than on a PC. They can also fail when a dependency assumes systemd, privileged namespaces, a device file, a package unavailable for Ubuntu ARM64, or a normal Linux kernel.
Optional: try a graphical display with Termux:X11
ROS command-line tools do not need a display. To try desktop applications, Termux:X11 requires both its Android app and companion Termux package, and the project documents using shared temporary storage with PRoot. This is an experimental route for ROS graphics, not a promise that RViz or a simulator will render correctly. See the Termux:X11 documentation.
In Termux, install the companion package and start the display server:
pkg install x11-repo
pkg install termux-x11-nightly
termux-x11 :1 &
Then enter Ubuntu with shared temporary storage and set the display:
proot-distro login ubuntu --shared-tmp
export DISPLAY=:1
For an XFCE desktop starting point inside Ubuntu:
apt install -y xfce4 dbus-x11
dbus-launch --exit-with-session xfce4-session
Package availability and speed vary. RViz also depends on graphics drivers and OpenGL support, so a visible X11 window does not ensure usable 3D rendering. If you see a black screen or color problems, the project documents these launch options:
Rank #4

- [360 ° Flexible Rotation Design] Comes with a rotatable lanyard ring that supports 360 ° free rotation, effectively solving the problem of twisted and tangled lanyards
- [Wide compatibility] The ultra-thin 0.02-inch design does not block the charging port at all, and both wired and wireless charging can be used directly without removing the pad. Compatible with most smartphones such as iPhone, compatible with various wristbands, lanyards, crossbody straps, and keychains
- [Durable and Portable Material] Premium rust-resistant stainless steel material with good flexibility, which not only avoids scratching the phone case, but also has excellent anti rust and anti fading performance
- [Multi scenario Practical] Paired with a lanyard or wristband, hands-free use can be achieved. The phone is within reach and not easily dropped, ideal for daily commuting and outdoor activities. Suitable for full coverage phone cases, does not support half coverage phone cases
- [Quality Service] If you find any damage or other issues with the product upon receipt, please contact us immediately. We will handle it quickly
termux-x11 :1 -legacy-drawingtermux-x11 :1 -force-bgraUse the phone as a ROS 2 network client
One of the stronger use cases is to run a lightweight node on Android while a Linux PC or robot computer handles simulation and hardware. Both machines need a working network path, and DDS discovery must be able to reach them. Check the domain and network interface:
echo "$ROS_DOMAIN_ID"
echo "$RMW_IMPLEMENTATION"
ip addr
ROS 2 nodes that should discover one another need matching ROS_DOMAIN_ID values. On the phone, start the demo talker; on the Linux machine, try:
ros2 topic list
ros2 topic echo /chatter
Discovery is not guaranteed on every Wi-Fi network. Client isolation, blocked multicast, Android firewall behavior, VPN routing, and mobile-network NAT can prevent nodes from finding each other. First test ordinary IP connectivity, such as ping <other-machine-ip>, then examine DDS configuration and network restrictions. A successful ping alone does not prove DDS discovery will work.
Why local robot hardware is the weak point
Android’s app sandbox and device-permission model are not equivalent to a conventional Ubuntu installation. A USB-OTG adapter may connect a device physically, but it does not ensure that a ROS node inside PRoot can open it through the usual Linux interface, such as /dev/ttyUSB0. USB serial, cameras, LiDAR, CAN, GPIO, udev rules, and privileged network configuration all need device-specific validation.
Termux:API exposes selected Android APIs to command-line tools; it is not a general substitute for kernel drivers, Linux device files, or udev. Android may be able to communicate with a particular USB device, but that does not mean ROS 2 inside Termux can use the device through its normal Linux driver.
For dependable hardware access, keep drivers and control nodes on a Linux robot computer, Raspberry Pi, Jetson, or Ubuntu PC. Use the phone for a dashboard, terminal, sensor publisher, or network client instead.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.Troubleshoot common failures
ROS packages do not appear in apt
Check the Ubuntu release, architecture, and package repository configuration:
Best Value
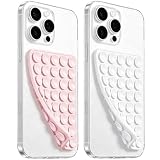
- 【PKYAA Double Sided Silicone Suction Phone Case Mount】PKYAA With Double Sided 40 Strong and Reliable individual suction cups, PKYAA provides a thicken and upgraded universal silicon suction mount for your phone.
- 【Friendly to Content Creators】If you are a content creator or an online influencer, you can create videos anywhere with this suction mount completely hands free with this silicone cell phone mount for cases.
- 【HANDS-FREE & Adhere to Mirrors】This Double Sided silicone suction phone case mount allows you to stick your phone to the mirror easily. No longer holding your phone in one hand to watch video tutorials while making up.
- 【Strong Grip on the Smooth Surface】You can easily hang your phone anywhere with a smooth surface. All you do is you clean off your phone and smooth surface. It is STURDY and it not only sticks to mirrors, it also sticks to windows, it sticks to refrigerators, tiles and other clean, flat surfaces.
- 【Press Down Firmly Every 30 Minutes】Use your palm or fingers to press the phone down firmly and check it's secure before letting go. Apply even pressure for a few seconds to allow the suction cup to adhere properly. To maintain the grip and prevent accidental falls, it's a good practice to periodically reapply pressure to the suction cup.
cat /etc/os-release
dpkg --print-architecture
uname -m
apt policy ros-jazzy-ros-base
The binary path described here targets Ubuntu 24.04 Noble on a supported architecture. A stale package index, unsupported image, or missing repository setup can make apt unable to find the package.
The ros2 command is not found
Source the environment and check the command path:
source /opt/ros/jazzy/setup.bash
command -v ros2
ros2 --help
If that fixes it, ensure the source line is in ~/.bashrc for future Ubuntu sessions.
rosdep initialization fails
If the command is missing, install python3-rosdep. If initialization reports an existing setup, run rosdep update and inspect /etc/ros/rosdep/sources.list.d/ rather than repeatedly running rosdep init.
Android stops a running node
Disable Termux battery optimization and keep the phone awake for sessions that need to persist. tmux can preserve a shell session across terminal detachment, but it cannot prevent Android from killing the app.
The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →RViz is black or crashes
Try the documented Termux:X11 rendering flags above. If that does not help, use ros-base without GUI tools or run RViz on a remote Linux machine.
A driver cannot open a device file
An error opening /dev/ttyUSB0 or a similar path is generally a device visibility or Android permission problem, not evidence that a ROS package is missing. Move the hardware driver to a Linux robot computer and communicate over ROS 2 networking.
When to use another setup
| Approach | Best fit | Main trade-off |
|---|---|---|
| Native Termux | Android command-line tools and lightweight utilities | Standard Ubuntu ROS packages are not designed for its environment. |
| Termux with PRoot Ubuntu | ROS 2 CLI learning, simple nodes, and experimentation without root | Slower and constrained by Android’s kernel, permissions, and background management. |
| Rooted Android with chroot | Users who knowingly need a more conventional Linux userland | Requires root and brings device-specific maintenance and security risk. |
| Ubuntu PC or mini PC | Reliable development, graphics, and hardware drivers | Requires another computer. |
| Robot computer plus Android client | Keeping drivers and control near the robot while using a phone for monitoring | Requires a separate robot computer and network configuration. |
| Remote workstation or cloud VM | Compilation, development, or simulation from an Android terminal | Needs a network connection; cloud use can incur charges and does not solve local hardware access. |
A community project also offers scripts for ROS 2 Humble and related Android setups. It is not an official ROS or Termux distribution, and its defaults may differ from the Jazzy-on-Noble path here. If you choose it, inspect the scripts and pin a release or commit rather than executing an unknown remote script directly: ros2_android on GitHub.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.

