
iTechGuides is reader-supported. When you buy through links on our site, we may earn an affiliate commission. As an Amazon Associate I earn from qualifying purchases. Learn more
If a drone motor stutters, hesitates, or stops, ESC desynchronization is one possible cause—but the symptom alone does not prove it. On an FPV quad, a single motor stalling while the others keep turning can cause a rapid roll or spin. If all motors drop out, investigate power loss or failsafe behavior as well. Start with propellers removed, compare the motors safely, inspect the wiring and hardware, then use logs or a motor swap to narrow down the fault before changing settings.
What ESC desync is—and what it looks like
An electronic speed controller (ESC) commutates a brushless motor by energizing its phases in sequence. A desync occurs when the ESC loses track of the motor’s commutation timing; the motor may stutter, lose power, or stall. The symptom is especially consequential on a multirotor because the flight controller may be unable to compensate for one motor that stops producing thrust. Oscar Liang’s desync guide, published February 23, 2024 and updated in February 2024, describes a rapid roll or spin as a characteristic crash pattern when one motor stalls and the others keep spinning.
A fall or a rough-sounding motor is not enough to identify desync. A battery-voltage drop, an overheated or damaged ESC, a damaged motor, or a failsafe can produce similar symptoms. If all motors stop together, investigate power and failsafe causes rather than assuming one ESC desynced.
Use the symptom to narrow the possibilities
| When or how it happens | What it may suggest | Useful next check |
|---|---|---|
| One motor stalls in flight while the others continue | Desync is plausible, but a motor, ESC, connection, or power fault can also be responsible. | Review Blackbox logs if available, then inspect the affected motor and ESC. |
| All motors stop or power disappears together | Failsafe or loss of power is more likely than a single-motor desync. | Check battery and power evidence and review the flight record. |
| A motor stutters only at the very bottom of a slider test | At very low output, slight stuttering can occur before the motor reaches a smooth spinning speed. | Raise the slider gradually and compare with the other motors. |
| Motors spin in the Motors tab but stutter when armed | A low idle setting is one possible explanation; a problem that appears only on arming is different from low-slider stutter. | Check the idle setting and inspect for mechanical or electrical issues. |
| The fault appears during a sharp throttle change or at high RPM | Motor and ESC capability, setup, or the abrupt speed change may be relevant. | Check motor/ESC compatibility and whether the symptom correlates with the same flight conditions. |
For FPV Blackbox, a motor that stops while its commanded signal climbs to its maximum is consistent with desync, according to the same guide. It is a clue, not proof of which component failed. If logs are unavailable, frame-by-frame DVR review may offer clues, but it also cannot identify the failed part by itself.
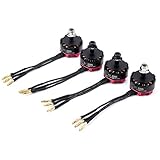
#1 Best Overall

- Item name: 2204 2300KV Brushless Motor CCW CW
- Suitable: for DIY Mini Multirotor Quadcopter 210 250 270 Robotcat Racing Drone
- Max. Thrust : 420g ; Max.Current : 12A ; Prop Shaft : M5*12mm
- Motor Dimension : 27.9*29.7mm ; Resistance : 0.112 ohm ; Idle Current : 0.6A
- Package Included: 1 Piece CW / CCW Motor or 2pcs CW + 2pcs CCW ( Optional)
Safe bench checks before changing settings
- Remove every propeller. Betaflight explicitly instructs users to remove props before plugging in a battery and testing motors. Keep them off throughout bench troubleshooting. If configuration or motor checks fail, do not fly until the issue is corrected. See the Betaflight setup guide.
- Confirm the output protocol and test context. Check that the selected ESC/motor protocol is supported by the hardware and configured correctly. Betaflight’s current setup guidance describes DShot300 and DShot600 as usual choices for many modern ESCs: it recommends DShot300 for slower processors and certain gyro setups, and DShot600 for faster processor setups. These are hardware- and setup-dependent recommendations, not universal desync fixes. Refer to the official setup guide for the applicable build.
- Raise each motor slider slowly. Compare the motors at the same slider levels. Betaflight notes that slight stutter at very low values can occur before a motor spins smoothly at a higher value. Record whether one motor behaves differently and whether the problem happens only when arming or also during slider testing.
- Inspect the motor and ESC. With the battery disconnected, look for visible damage, poor connections, or bridged ESC motor solder pads. Check that motor screws are not long enough to reach the windings. The motor-stuttering and ESC test guide, dated December 6, 2024, covers these checks.
- Check power and operating conditions. Look for evidence of battery-voltage loss or an overheated ESC, and consider whether the motor is damaged. Those issues can imitate desync and should be considered before adjusting desync-related settings.
- Use logs or localize the fault with a swap. If the problem is confined to one motor, a motor swap can show whether the symptom follows the motor or stays with the arm/ESC. Betaflight’s 3D setup guide includes this localization approach in its specific 3D setup context. Disconnect power and work carefully; do not fly until the cause is understood.
What to change when evidence points to a setup issue
Change one setting at a time, record the original value, and validate the result with props removed before any flight test. The correct setting depends on the flight-controller and ESC firmware, protocol, motors, and build. Do not apply BLHeli-specific advice to an ESC running incompatible firmware.
Idle setting: distinguish arming stutter from desync
If motors spin in Betaflight’s Motors tab but stutter when the quad is armed, the stuttering guide suggests checking for an idle that is too low and testing the default 5.5% value. For suspected desync, the desync guide suggests trying a somewhat higher idle of 6.5–7. These figures address different symptom contexts; they are not universal target values. Confirm which idle setting and units apply to your firmware before making a change.
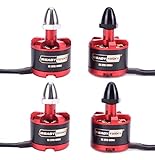
Rank #2
- This motor can support 3-4s lipo battery, more powerful and better faster.
- Come with soldered 2mm banana plugs,save welding trouble.
- Enhanced anti off u ring for safety and stability. Active cooling fins greatly reduce motor temperatures.
- Stainless steel motor shaft, CNC machined aluminum case, more powerful.
- This 2205S 2300KV brushless motor is perfect for your 210 220 250 280 FPV racing drone quadcopter.
ESC startup, ramp-up, and demagnetization compensation
For supported BLHeli setups, the desync guide discusses experimenting with startup or ramp-up power and demagnetization compensation. It describes lower startup values as a starting point, with adjustment if props hesitate on arming, and notes that high demag compensation can improve recovery at a performance cost. These are firmware-specific experiments, not settings to copy blindly. Confirm that your ESC firmware supports the controls and follow its documentation.
The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →Protocol, electrical noise, and motor/ESC matching
- Protocol: Confirm compatibility and configuration rather than treating a protocol change as a guaranteed cure. Betaflight’s protocol and speed guidance is in its setup documentation.
- Electrical noise: A low-ESR capacitor on the ESC power input is one possible noise-reduction measure described in the desync guide. Its voltage rating, polarity, physical fit, and compatibility must match the specific battery and ESC; there is no one value established for every build.
- Motor and ESC capability: Excessive RPM relative to ESC capability and abrupt speed changes are potential contributors. Check whether the components are suitably matched and whether the symptom tracks high RPM or sudden throttle changes.
When to use a multimeter or replace hardware
If visual inspection suggests ESC damage, a digital multimeter with continuity mode can help assess the board. The ESC troubleshooting guide describes continuity checks across ESC power and motor pads when investigating possible MOSFET damage. Follow the meter and aircraft documentation, disconnect power, and interpret a continuity result as an indication—not a complete diagnosis or guarantee that the MOSFET is faulty.
Rank #3
- ★This Motors are less noise and stable.
- ★With 3.5mm bullet conenctors,save welding trouble.
- ★Fit for F330 F450 F550 S500 S550 Quadcopter.
- ★Due to different people use different frames and it requires screw sizes are also different, so it didn't come with screws.
- ★★★Suggest to use our 1045 propellers,ASIN:B0823NNTKD
MOSFET replacement is board-level repair that may require professional equipment, substantial soldering skill, and the exact component model. For many pilots, a compatible replacement ESC is more practical if damage is indicated. Verify compatibility with the battery, current requirements, motors, flight-controller setup, firmware, board dimensions, and wiring before installing one.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.Keep calibration instructions specific to the ESC
Calibration guidance is not interchangeable across ESC protocols. ArduPilot’s ESC calibration documentation concerns calibration setup; PWM calibration instructions should not be applied to DShot or CAN configurations without checking the instructions for that aircraft and ESC. For Betaflight builds, use the relevant Betaflight and ESC documentation rather than assuming another firmware’s calibration steps apply.
Quick Recap
Best Value

- 【Clear 2K Camera & Real-Time FPV View】Capture clear photos and videos with the built-in 2K HD camera and adjustable 90° lens. Connect the drone to the BLINORY GO app to enjoy real-time FPV viewing, save your footage directly to your phone or SD card, and easily share family moments, travel views, or outdoor fun.
- 【Easy to Fly for Beginners】Designed for first-time flyers, this beginner drone features one-key takeoff/landing, altitude hold, headless mode, emergency stop, 3 speed modes, 360° flips, gesture selfie, and waypoint flight. Use the remote control or app to fly with confidence, whether practicing indoors or enjoying casual outdoor flights.
- 【36 Min Flight Time with 2 Batteries】This mini drone comes with 2 enhanced rechargeable batteries, providing up to 36 minutes of total flight time under ideal conditions. The low-battery alert helps remind you when it is time to return, so beginners can enjoy longer practice sessions with better control and fewer interruptions.
- 【Brushless Motor for Stable & Smooth Flight】Built with upgraded brushless motors, this camera drone delivers more stable performance, lower noise, longer motor life, and smoother flight than ordinary brushed-motor drones. Optical flow positioning and altitude hold help keep the drone steady for clearer photos, smoother video, and easier beginner control.
- 【Portable Starter Kit with Full Support】Weighing under 250g, this foldable drone requires no FAA or Remote ID registration for recreational use. The carrying case keeps the drone, remote, batteries, propeller guards, and accessories organized for travel or gifting. Before first flight, fully charge the batteries, manually unfold the arms, install the propeller guards, calibrate the drone, and start in low-speed mode. Our support team is available to help with setup and troubleshooting.
Rank #4

- 1. SUNFUN2306 brushless motor is the upgraded motor, 12N 14P high torque motor design, which is smooth, reliable and powerful.
- 2. The motor is characterized by support 2~6S lipo. Suitable for multicopter, RC aircraft, drone.
- 3. 2306 Motor 1900KV, motor mount M3*16, which is compatible with 5inch propeller.
- 4. FPV brushless motor provides the most incredible power and thrust in the lightest weight. Give you a more satisfied experience with your model.
- 5. Each rotor was dynamically balanced with high speed. High purity copper windings maximize efficiency, good insulation and heat resistance.
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

