
The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →iTechGuides is reader-supported. When you buy through links on our site, we may earn an affiliate commission. As an Amazon Associate I earn from qualifying purchases. Learn more
A drone-swarm Concept of Operations (CONOPS) is the operational blueprint for using multiple unmanned aircraft as one coordinated team. It states what mission the swarm performs, how many and which aircraft participate, who supervises them, what autonomy is allowed, how communications and airspace are managed, and what happens when something goes wrong. A useful CONOPS connects those decisions to measurable outcomes, legal permissions, safety controls, logistics and contingency procedures; it is much more than a flight plan or a description of swarm software.
What “drone swarm” means
Terminology is not completely settled, so a CONOPS should define “swarm” at the start. The Federal Aviation Administration (FAA) baseline quoted and analyzed by Army University Press in Defining Swarm (2025) is “an operation of more than one Unmanned Aircraft (UA) in which all UAs operate in unison to commands from one Pilot in Charge (PIC), who commands them all through a common link.” That definition emphasizes a single responsible pilot and a common control path.
Army University Press also proposes a military-context definition: “An assembly that operates cooperatively to commands from a single operator in charge through a common architecture.” Military discussions commonly add autonomy, decentralization, adaptation and resilience to the basic FAA idea. The definition matters because it determines who has authority, what technology must be tested and which safety obligations apply.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Swarm versus formation
A formation is primarily a spatial arrangement: aircraft hold specified positions or geometry. Each aircraft may still have its own operator and independent mission. A swarm is an operational team. Vehicles can exchange information, divide tasks, reassign work, adapt to changing conditions and continue under a shared command architecture. A swarm can use formations, but a formation alone does not prove swarm behavior.
#1 Best Overall

- 1. Unique DIY Drone:This DIY drone integrates optical flow positioning modules, video modules, and high-power brushless motors.The assembly process takes approximately 1.5 hours and requires patience and hands-on skills. Recommended for users aged 14 and above. Difficulty level: 5/5.
- 2. A Project Worth Showcasing:Packed with extensive foundational knowledge about drones, this kit allows you to deeply understand drone technology during assembly. Master the principles and confidently showcase your expertise, gaining admiration from friends.
- 3. Multifunctional Flight Experience:360° flips,One-click takeoff/landing,Headless mode,Speed adjustment,Optical flow positioning,Real-time video transmission,Perfect for indoor/outdoor flight performances,Operation difficulty : 5/5(practice required for proficiency).
- 4. Worry-Free Flying:Includes spare propellers for quick post-crash replacements.Flight time can be up to 30 minutes.【about LED】Slight flight control algorithm differences across batches. If LEDs won't light up, switch to the other installation mode. No impact on flight.
- 5. Educational Value:The detailed manual explains drone fundamentals and serves as a reference for STEM project plans or curriculum design. Includes editable PowerPoint teaching materials to support educators.
| Question | Swarm | Formation or coordinated group |
|---|---|---|
| Control | Usually one operator or command authority supervises the group through a common architecture. | Multiple operators may control separate aircraft. |
| Coordination | Vehicles can share state, allocate tasks and respond collectively. | Coordination may be limited to position, timing or verbal instructions. |
| Adaptation | Rules can reassign tasks after a vehicle, link or sensor changes. | Members may continue their preassigned flight unless an operator intervenes. |
| Defining test | Cooperative mission behavior under a shared command model. | Maintaining a pattern or operating nearby. |
What a swarm CONOPS contains
A CONOPS explains how the mission is actually conducted from preparation through recovery and assessment. It should be readable by operators, engineers, airspace authorities, safety staff and, where applicable, military commanders or regulators. The following elements belong in the document.
Mission, environment and desired effects
Begin with the operational problem. State the area, time window, weather assumptions, terrain, expected traffic, threat or hazard environment and the effect the swarm must produce. Examples include persistent observation, distributed sensing, communications relay, search coverage or delivery of several payloads. Define success with observable measures such as area searched, detections confirmed, coverage maintained, latency, data quality, aircraft recovered or mission time completed.
Separate the primary effect from supporting activities. A swarm that searches a large area may need individual aircraft to map sectors, relay data, avoid one another and return for battery rotation. Each behavior should support a stated mission outcome rather than exist because the platform can perform it.
Composition and scale
List aircraft types, sensors and payloads, launch and recovery equipment, command stations, communications relays, spare vehicles, batteries, maintenance tools and data infrastructure. Identify which members are interchangeable and which have unique capabilities. Include planned fleet size, reserve capacity, crew positions and the maximum number of vehicles one operator is expected to supervise.
There is no universal numerical threshold for a swarm. The FAA wording requires more than one aircraft, while military programs may envision much larger teams. DARPA’s OFFSET program describes an ambition of “upwards of 250” small unmanned aircraft systems and/or unmanned ground systems. That is a program scale goal, not a rule that every swarm must contain 250 platforms. The practical number depends on mission complexity, autonomy, communications, endurance, airspace and operator workload.
Command and control
Show the authority chain and the control interfaces. Name the person or role responsible for the operation, who may approve a launch, redirect a task, change a geofence, authorize an abort and declare the mission complete. Explain whether one operator supervises all vehicles directly or assigns groups to subordinate operators.
Describe the control architecture as centralized, distributed or hybrid. A centralized design may simplify authorization but can create a single point of failure and a communications bottleneck. A distributed design can let vehicles continue useful work when a link is degraded, but it requires carefully bounded rules and stronger verification. A hybrid design often keeps mission authority centralized while distributing collision avoidance, local navigation or task allocation.
Outdated Drivers Are Slowing You Down
One free scan finds every outdated or missing driver and matches the right update for your exact hardware.Free scan · exact hardware matchWindows Errors? Fix Them Before They Spread
Repair common Windows errors and clear accumulated junk for a smoother, more stable PC - no reinstall needed.Free scan · no reinstallRank #2
- Unique DIY Drone: This DIY drone integrates advanced optical flow positioning modules, video modules, and high-power brushless motors. You need to complete everything from every single screw to the overall assembly, and the assembly takes approximately 1.5 hours. It is recommended for users over 14 years old. Difficulty level: 5 stars (out of 5 stars).
- An Impressive Project to Show Off: This project is packed with extensive basic knowledge of drones. It enables you to acquire more profound knowledge about drones during the assembly process, allowing you to boast more confidently and draw more admiration from others.
- Multi-functional Flight Experience: It offers five amazing flight functions: 360° roll, one-click takeoff and landing, headless mode, speed adjustment, optical flow positioning, and real-time video viewing, adding infinite fun to your flight experience and allowing you to perform flight shows easily in the office or at home. Operation Difficulty: 5 stars (Proficiency in flight requires practice).
- Worry-free Flight: Spare propellers are included to ensure that you can quickly replace them even if you encounter an accident during flight and continue to enjoy the fun of flying. The single flight duration can reach 30 minutes.
- Educational Significance: The detailed instruction manual not only introduces the basic principles of drones but is also very suitable as reference material for STEM project plans or curriculum design. In addition, we provide easily modifiable PPT courseware to assist your educational work.【about LED】Slight flight control algorithm differences across batches.If LEDs won't light up, switch to the other installation mode.No impact on flight.
Autonomy and human supervision
Write an explicit autonomy matrix rather than using “autonomous” as a blanket label. For every important function, identify whether it is automatic, delegated under preset rules or requires human approval.
| Function | Possible CONOPS treatment |
|---|---|
| Navigation and position keeping | Automatic within an approved volume and speed limit. |
| Collision avoidance | Automatic emergency maneuvering with operator notification. |
| Task assignment | Algorithmic allocation within operator-approved mission goals. |
| Geofence or route change | Human approval unless a predefined emergency rule applies. |
| Payload use or target action | Human authorization, with an auditable record, where the mission or law requires it. |
| Abort and recovery | Automatic trigger for defined hazards, with operator override only where safe. |
The CONOPS must also state how the operator monitors health, location, intent, remaining endurance and exceptions. A human who is technically in charge but cannot understand the swarm’s state does not have meaningful supervision. Define alert priorities, maximum workload, handover procedures and the conditions that force a reduction in swarm size or mission scope.
Coordination and interoperability
Document the common link, inter-vehicle communications, message formats, timing and synchronization, identity management and software interfaces. Explain how members share position, velocity, task status, sensor confidence, fuel or battery state and emergency status. Specify what information is retained if the external link fails and how vehicles prevent conflicting commands.
Interoperability includes more than radio compatibility. State how the swarm exchanges data with the command station, airspace services, other aircraft, ground teams and post-mission systems. Identify version control, authentication, encryption, time sources, update procedures and behavior when a participant cannot parse a message or loses synchronization.
Recommended Free Tools
How a swarm operates from launch to recovery
A CONOPS should describe a repeatable operating cycle. The exact checklist varies by platform, but the sequence below exposes decisions that are often missed.
- Plan and authorize. Define the mission volume, routes, tasks, weather limits, communications coverage, airspace permissions, emergency landing areas and staffing. Load only the software, maps, geofences and mission data approved for that operation.
- Inspect and configure. Verify airframes, batteries, payloads, navigation sensors, clocks, data links, software versions and identification. Record serial numbers and assign each vehicle a role or capability set.
- Brief the team. Confirm the pilot in charge, autonomy limits, call signs, lost-link behavior, abort authority, handover method, emergency contacts and the conditions that prevent launch.
- Establish the control network. Authenticate vehicles, test the common link and inter-vehicle path, check command latency and confirm that every member reports position, health and configuration correctly.
- Launch and assemble. Use a defined order, spacing and altitude profile. The swarm should enter its operating volume only after the system confirms that all required members are accounted for and collision-avoidance functions are active.
- Execute and supervise. Assign sectors or tasks, monitor exceptions and compare actual coverage, endurance and link quality with the plan. The operator may redirect the group, but each redirection must remain inside approved constraints.
- Manage changes. State how the swarm responds to weather, traffic, a new priority, a failed sensor, a low battery or a missing member. Reallocation rules should identify which vehicle assumes the task and when the mission must be reduced or stopped.
- Recover and close. Specify return routes, landing order, battery and payload handling, data transfer, evidence preservation, maintenance inspection and a formal end-of-mission declaration.
Airspace, safety and accountability
Safety controls are operational rules, not appendices. Define the approved altitude and geographic area, separation standards, geofences, detect-and-avoid behavior, emergency landing sites, weather minima, lighting or identification requirements and procedures for unexpected traffic. State who can stop the mission and how that command reaches every vehicle.
Lost-link behavior must be specific. A vehicle might hold, return, land, join a recovery route or continue a bounded task, but the choice depends on airspace, terrain, endurance and the risk to people. Document timing thresholds, alternate links, navigation degradation limits and what happens if only part of the swarm loses contact.
Rank #3
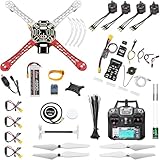
- 𝐘𝐨𝐮𝐫 𝟏𝐬𝐭 𝐃𝐈𝐘 𝐃𝐫𝐨𝐧𝐞 - F450 is the best DIY drone for both beginners to learn the basics and experts to conduct research or secondary development.
- 𝐌𝐨𝐫𝐞 𝐂𝐚𝐩𝐚𝐜𝐢𝐭𝐲 & 𝐌𝐨𝐫𝐞 𝐒𝐩𝐚𝐜𝐞 - Wheelbase: 450mm, Maximum take-off weight: approx. 1.8 kg. It has enough space for flight control, Raspberry Pi, camera, sensors, etc.
- 𝐍𝐞𝐰𝐛𝐢𝐞 𝐅𝐫𝐢𝐞𝐧𝐝𝐥𝐲 - We have prepared a quick start guide for new players that will assist you with the assembly and calibration of a DIY drone. Please contact us if you need it.
- 𝐁𝐫𝐚𝐧𝐝 𝐏𝐚𝐫𝐭𝐬 - We use parts from brands for stable and reliable quality. Free replacement for quality problems within 3 months.
- 𝐅𝐥𝐢𝐠𝐡𝐭 𝐂𝐨𝐧𝐭𝐫𝐨𝐥 𝐍𝐎𝐓 𝐈𝐧𝐜𝐥𝐮𝐝𝐞𝐝 – Assembling a complete drone requires flight controls, which are not included in this kit. You can choose the flight control according to your needs and budget.
Keep records that support accountability: authorization, operator assignments, software and configuration versions, commands, alerts, vehicle health, link interruptions, deviations, aborts and recovery results. A post-flight record should allow investigators to reconstruct what the system knew, what the operator saw and why the swarm acted as it did.
Civilian and commercial swarm CONOPS
For civilian operations, especially beyond visual line of sight (BVLOS), the CONOPS must connect flight procedures to an authorization and traffic-management pathway. The FAA’s Drone Integration: Concept of Operations (May 2025) presents a vision for routine, scalable BVLOS operations over the next decade. Its primary focus is operations below 400 feet above ground level (AGL), while also addressing uncontrolled and controlled airspace, aircraft, infrastructure, assumptions and future operating concepts.
The FAA defines UTM as a collaborative ecosystem for flight planning, authorization, surveillance and conflict management for low-altitude unmanned aircraft, particularly BVLOS operations. A civilian swarm CONOPS should therefore identify:
- Which UAS Service Supplier or equivalent service provides flight planning and authorization.
- What surveillance data the operator supplies, receives and retains.
- How the system detects conflicting operations and resolves priority.
- How coverage gaps, service outages and stale data are handled.
- Which permissions, waivers or exemptions apply to the aircraft, operation and location.
- How the operator demonstrates safety, competence and continuing compliance.
The FAA’s Near-Term Approval Process reviews proposals from UAS Service Suppliers and Supplemental Data Service Providers and may provide safety credit relevant to waiver or exemption applications. That process does not automatically authorize a particular swarm; the applicant still needs an operation-specific case and evidence.
The EU U-space Concept of Operations provides a comparable, user-oriented traffic-management model. Its consolidated edition incorporates regulatory evolution and urban-air-mobility needs, illustrating how a CONOPS can serve as a shared operating model among operators, service providers and regulators. A European document should map the swarm’s services, data responsibilities and authorization steps to the applicable U-space framework rather than assume that an FAA-style process applies.
Do these 3 things before closing this tab:
1Scan for outdated or missing drivers - takes under a minute2Repair Windows errors before they cause bigger problems3Fix the driver behind crashes, sound loss and screen glitchesMilitary and defense considerations
Military CONOPS work must resolve questions that a simple commercial flight plan does not: how many and what kinds of systems are needed, how authority is delegated, how vehicles cooperate under uncertainty, how tactics adapt and how the mission continues when communications or navigation are contested.
DARPA’s OFFSET program illustrates the design challenge. Its objectives include tools to generate and evaluate swarm tactics, an open systems architecture and a human-swarm interface for directing potentially hundreds of unmanned platforms. The CONOPS implication is that tactics development, operator workload, communications resilience and mission-level tasking must be designed together, then tested at realistic scale.
Rank #4

- 5 in 1 DIY Drone Build Kit: This 5 in 1 DIY Drone Build Kit is an exciting and educational toy that provides kids with a fun and engaging way to learn about drones and STEM concepts. With 159 easy-build pieces, kids can build their own drones in different styles and colors, improving their imagination and creativity, get start in RC drone!
- Easy Control for Kids & Beginners: The drone comes with several features that make it easy to fly for kids and beginners, such as Altitude Hold, Headless Mode, One Key Take-off/Land, Low Power Warning, and Emergency Stop functions. keep the drone hovers at a certain height, you can the control the fly direction at will.
- Fun to Play: Equipped with 3D flip and 3 Speed Modes, Kids can also perform 3D flip stunts in four directions and control the drone's speed in three different modes. playable with all skill levels and all ages.
- Great Gift for Boys&Girls: The pieces of the drone kit are sturdy, durable, and made of premium quality and non-toxic ABS plastic. The drone is equipped with four propeller guards that protect kids from spinning propellers and the drone from damage.
- Quality and non-toxic ABS plastic. Equipped with 4 sides propellers guards which protects kids from spinning propellers and protects drone from damage. It is no doubt a Great gift for birthday, Children's Day, Christmas, kids will love the building and get the drone to fly!
A Federal Register notice describes swarming UAS capabilities such as autonomous coordination, collision avoidance, formation maintenance, dynamic response to operational or threat changes and synchronized targeting where systems are weaponized. Those are behaviors to specify as authorities, constraints, evidence and contingencies; the notice does not establish that every swarm system possesses all of them. A responsible CONOPS states exactly which behaviors are available, which are prohibited and what test demonstrates each claim.
Resilience and contingency branches
Write a branch for every failure that could change the mission or create a hazard. At minimum, cover:
- Weather: limits, forecast updates, shelter or diversion routes and the trigger for early recovery.
- Navigation degradation: fallback sensors, bounded movement, separation rules and landing or return criteria.
- Communications denial: alternate links, local coordination, time limits and a safe termination behavior.
- Vehicle loss: task reassignment, airspace clearance, payload disposition and a reassessment of whether the remaining swarm is still safe.
- Cyber incident: authentication failure, suspected compromise, isolation, key rotation and evidence preservation.
- Unexpected traffic: alert priority, avoidance maneuver, communication with other users and mission suspension.
- Human error or overload: relief operator, command confirmation, simplified control mode and mandatory pause.
Each branch should identify the trigger, the automatic response, the human decision, the responsible role, the time limit and the recovery record. “The operator will handle it” is not a contingency procedure.
Measuring whether the CONOPS works
Assessment should cover both mission performance and operational risk. Useful measures include task completion, coverage, detection or data quality, time on station, command latency, link availability, number of operator interventions, vehicle utilization, battery reserve at recovery, separation violations, false alerts, aborted sorties and successful recovery after failures.
Test progressively: simulation, hardware-in-the-loop, a small number of aircraft, representative traffic and weather, then the planned scale. Include degraded communications, navigation errors, vehicle attrition, software version changes and handover between operators. A result is meaningful only when the scenario, fleet size, environmental conditions and success criteria are recorded.
How to compare two swarm CONOPS
Do not compare documents by vehicle count alone. Use the same questions for each concept:
| Comparison axis | What to examine |
|---|---|
| Span of control | How many vehicles one operator can supervise safely, under normal and degraded conditions. |
| Autonomy boundary | Which actions are automatic, delegated or human-approved, and how overrides are recorded. |
| Architecture | Centralized, distributed or hybrid coordination; common-link assumptions; interoperability. |
| Resilience | Behavior during link loss, navigation degradation, cyber attack, weather and vehicle attrition. |
| Airspace integration | Authorization, surveillance, deconfliction, detect-and-avoid and UTM or equivalent interfaces. |
| Mission persistence | Endurance, battery rotation, payload exchange, launch and recovery capacity and maintenance. |
| Safety and accountability | Geofencing, abort logic, human responsibility, logs and post-mission review. |
| Scalability and cost | Whether staffing, communications, infrastructure and procedures remain workable as the fleet grows. |
Common mistakes when writing a swarm CONOPS
- Defining a swarm only by quantity. Two aircraft may qualify under one definition, while a larger fleet may merely be several independent flights.
- Calling every automation feature autonomy. Name the decision, authority and limit for each automated behavior.
- Ignoring operator workload. A theoretical span of control is not evidence that one person can supervise safely.
- Treating communications as guaranteed. Specify degraded and denied-link behavior, not only normal operation.
- Leaving regulation until the end. For civilian BVLOS work, authorization, surveillance and conflict management shape the design from the beginning.
- Confusing a demonstration with an operational concept. A successful scripted flight does not establish scalable procedures, resilience or safety.
- Omitting recovery and sustainment. Batteries, maintenance, data handling and launch cycles determine whether the mission can persist.
A strong drone-swarm CONOPS is therefore a negotiated operating model: it aligns mission effects, people, aircraft, autonomy, communications, airspace services, safety controls and contingencies. It should make a reader able to answer not only “what can these drones do?” but also “who is responsible, what happens next and how do we know the operation is safe and successful?”
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

