
iTechGuides is reader-supported. When you buy through links on our site, we may earn an affiliate commission. As an Amazon Associate I earn from qualifying purchases. Learn more
Choose an autonomous underwater vehicle (AUV) when the mission is a repeatable survey, mapping run, or environmental measurement that can be planned in advance and recovered after onboard recording. Choose a remotely operated vehicle (ROV) when a surface pilot needs live video, continuous control, close maneuvering, sampling, cutting, lifting, or a manipulator. UUV is the umbrella term that includes both kinds of underwater robots. The right choice depends less on the label than on whether your mission requires persistent human control and physical intervention.
What UUV, AUV and ROV mean
UUV is the family name
Unmanned underwater vehicle (UUV) is a broad category for an underwater craft that operates without a person aboard. NOAA’s uncrewed-marine-systems policy places remotely operated and autonomous craft in this larger uncrewed family. In practical procurement language, “UUV” may refer to either an autonomous vehicle or a remotely piloted one, so a specification should always state the control method.
AUV is an autonomous, untethered UUV
An autonomous underwater vehicle (AUV) carries its own energy, navigation systems, sensors and computer. It follows a pre-planned mission without a continuous command cable to the ship. Sensors collect measurements, photographs, sonar data or other observations into onboard storage. The vehicle later surfaces, holds a recovery position or follows another recovery procedure so the crew can retrieve the data and the vehicle.
ROV is a tethered, remotely operated UUV
A remotely operated vehicle (ROV) remains connected to a surface vessel through an umbilical. Pilots send commands down the tether and receive video, sonar and instrument readings in real time. The tether can also deliver power on many systems, allowing long work periods without relying solely on an onboard battery. ROVs range from small inspection units to large work-class machines with multiple manipulators.
#1 Best Overall
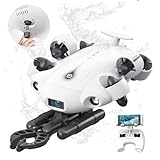
- 4K 60FPS High Frame-rate Camera: Create epic footage and wonderful underwater moments with V-EVO's upgraded camera system, achieving professional-class shots with ease and enhanced smoothness.
- Removal SD Card: The new version is a removable SD card, providing you with more convenient gameplay and storage functions. The FIFISH V-EVO's hydrodynamic, fluid, and rugged water droplet design ensures minimal resistance against ocean currents, allowing for longer dives. An attachment port accommodates a variety of tools, enabling integration and versatility for various tasks and scenarios
- 360° Omnidirectional Mobility: Reach beyond the limits of traditional methods, and achieve full 360° freedom in underwater mobility, hovering and posture holds. Turn your creative imagination into cinematic 4K imaging reality.
- 5000 Ultra-bright Lumen LEDs: FIFISH V-EVO comes equipped with a pair of combined 5000 lumens · 5500K white LED lights. Optimize your vision across the deep sea and restore the colors of the world below, especially through dark and turbid environment.
- 166° Ultra Wide Lens: See the bigger picture and discover an extraordinary world below. Go beyond a conventional underwater lens to achieve a greater impact with your visuals.
Why the distinction matters
Calling both systems “underwater drones” hides the operational trade-off. An AUV exchanges live access for freedom from a cable and efficient area coverage. An ROV exchanges tether drag and a larger support spread for immediate human judgment and physical work. That trade-off determines the vessel, crew, navigation plan, data workflow and risk controls you need.
UUV vs ROV: the differences that affect a mission
| Decision axis | AUV (autonomous UUV) | ROV (tethered UUV) |
|---|---|---|
| Control | Runs an uploaded mission plan with limited intervention while submerged. | Pilots steer and operate equipment continuously from the surface vessel. |
| Communications and latency | No continuous command link is required; underwater data is normally retrieved after recovery. | The umbilical carries commands and returns live video and instrument information, subject to the vessel’s surface communications. |
| Coverage and endurance | Untethered travel makes parallel survey lines and broad-area mapping practical; endurance is limited by onboard energy and mission settings. | Can remain on a worksite while powered and supported from the vessel, but tether management limits range and movement. |
| Navigation and recovery | Needs dependable underwater navigation, a recovery strategy and a way to find the vehicle after it surfaces or reaches its recovery point. | Pilots use live sensor feedback and the tether to keep contact, but launch, umbilical handling and recovery are vessel-intensive. |
| Entanglement exposure | No worksite tether reduces snagging and drag during open-water surveys. | The umbilical can snag on structures, lines, wreckage or seabed features and requires a trained tether team. |
| Payload and intervention | Best suited to cameras, sonar and scientific sensors that log data; physical intervention is limited by the vehicle’s design. | Commonly carries cameras, lights, sonar and manipulators for inspection, sampling, cutting, retrieval and lifting-hook attachment. |
| Depth and environment | Rating varies by vehicle and payload; pressure, cold, darkness and corrosion affect every deep-water design. | Rating varies by vehicle and tether system; the umbilical and surface equipment add additional engineering constraints. |
| Vessel and crew | Requires a launch-and-recovery arrangement, mission operator and post-recovery data process; the exact support spread is vehicle-specific. | Requires a suitable vessel, pilot station, tether-management equipment and a crew able to operate the vehicle and its tooling. |
| Cost profile | Can reduce time on site for repeated surveys, but navigation, recovery and data-processing capability are essential investments. | Costs include vessel time, pilots, tether operations and tooling, offset by immediate decisions and intervention capability. |
These are system-level tendencies, not universal specifications. Depth, endurance, sensor quality, navigation accuracy and payload capacity differ substantially among vehicle classes and mission packages.
When an AUV is the better choice
Repeatable survey lines and bathymetry
AUVs are a strong fit when the job is to collect measurements along planned lines or a grid. Bathymetric mapping, seabed characterization and route surveys benefit from a vehicle that can run consistent tracks without an umbilical sweeping across the bottom. The operator defines the line spacing, altitude, speed, sensor settings and abort rules before launch, then reviews the logged data after recovery.
The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →Habitat, wreck and environmental mapping
Untethered operation lets an AUV cover an area without tether drag limiting its distance from the vessel. Cameras, side-scan or multibeam sonar, water-quality instruments and other sensors can build a map of habitat, a wreck site or an environmental condition. The vehicle is most useful when the objective is observation rather than touching or changing the target.
Situations where a cable would restrict coverage
In open water, around dispersed targets or along long transects, an umbilical can add drag, restrict turning radius and create snag hazards. An AUV can move independently of the ship while the vessel follows a recovery plan. This does not remove operational risk: the team must account for currents, navigation drift, lost-vehicle procedures and the possibility that the vehicle will not surface at the expected location.
Repeated data collection
If the same area must be measured on a schedule, a stored mission plan can improve repeatability. The team can compare runs using the same line geometry and sensor settings, provided navigation, calibration and environmental conditions are documented. An AUV is not automatically more accurate; repeatability depends on the vehicle’s navigation solution, payload calibration and quality-control process.
When an ROV is the better choice
Live inspection of a known structure
An ROV is appropriate when an operator must react to what the camera reveals. Hull inspection, subsea infrastructure checks, pier and bridge work, cable or pipeline examination and wreck documentation often require a pilot to hold position, change viewing angles and revisit a feature immediately. Live video allows the team on the vessel to make decisions while the vehicle is still at depth.
Do these 3 things before closing this tab:
1Repair Windows errors before they cause bigger problems2Scan for outdated or missing drivers - takes under a minute3Clear out junk files and repair common Windows errorsUncertain targets and close maneuvering
When the target location, shape or condition is not fully known, a pilot can adapt the search pattern in real time. Thrusters and live sonar or camera feedback help the operator approach an opening, structure or debris field without committing the entire mission to a pre-programmed path. The tether team must still manage slack and routing to avoid contact with the target.
Rank #2

- 【More clearer And More Stable】GLADIUS MINI S captures epic moments with 4K HD video and 12 MP photos. It also comes with a 1/2.3 SONY CMOS, anti-video-shake feature, so you can record the beauty of the mysterious underwater world with more stable and vivid UHD video. With the combination of F2.8 lens and 2 x 1200 lumens LED lights, GLADIUS MINI S underwater drone can capture underwater details even in low light
- 【Up to 4 Hours of Flight Time】Equipped with two 4800 mAh batteries, GLADIUS MINI S underwater drone only takes 3.5H to fully charge the drone, It can reach up to 4 hours of flight time, This will also work for long hours of construction inspections and underwater exploration; In addition, the main unit is equipped with a 64GB SD card, but the GLADIUS MINIS underwater drone can support up to 512GB SD card, making it more convenient for downloading data, while also storing more photos and videos
- 【Move freely in the water】The GLADIUS MINI S underwater drone with camera is equipped with 5 thrusters, a maximum speed of 4 knots; with a maximum depth of 330 ft and a maximum horizontal shooting radius of up to 330 ft; The mini S underwater drone also adopts patented motor technology to prevent rolling in pebbles and sand; It works perfectly and reliably even in complex underwater environments with all patterns to meet your photography, Observing, and work needs at any angle you want
- 【Compatible with Sophisticated Attachments】GLADIUS MINI S underwater drone weighs only 6 lbs. which allow single-person operation and Quick- Deployment within 3 minutes; It supports a variety of mounts such as grabber claw, GoPro camera, etc.; GLADIUS MINI S is an underwater drone that meets the needs of various applications such as underwater photography, scientific exploration, and safety inspection, etc. Ideal for light industrial applications for a wide variety of professionals
- 【Stable Connection Remote Control】Underwater Camera Equip with wired connection remote controller to make the drone able to work stably and continuously without signal disconnections; Depth, temperature, and other parameters can be recorded at the same time; The App also supports live broadcasting or social media sharing, the ability to take photos while recording video, time-lapse photography, as well as quick editing features and HDMI output to other monitors or devices as well as save it on a removable SD card
Sampling, salvage and intervention
ROVs commonly carry manipulators and purpose-built tools. NOAA lists object identification, hull inspection, retrieval, line cutting and attaching lifting hooks among ROV uses. A manipulator can collect a sample, turn a valve, remove an obstruction or position a tool while the pilot watches the result. These tasks require more than a camera: check the vehicle’s payload interfaces, hydraulic or electrical capacity, tool reach, force limits and operator training.
Work that cannot wait for recovery
If the mission requires a decision or physical response before the vehicle returns to the surface, an ROV’s live control path is decisive. An AUV can log a damaged component, but it generally cannot confirm the finding with a pilot or perform a repair during the same dive unless it was specifically designed for that intervention.
Use a hybrid or staged mission when both strengths matter
A common plan is to use an AUV for broad-area detection and an ROV for confirmation and intervention. The AUV maps the seabed or identifies anomalies, reducing the area that the ROV must inspect. The ROV then provides live imagery, samples a target or attaches recovery equipment.
- Survey: Run the AUV over the defined area with the sensors and navigation settings needed to locate features.
- Process: Recover the vehicle, validate navigation and sensor quality, and produce target coordinates with uncertainty estimates.
- Inspect: Launch the ROV with a route and tooling plan based on those targets, while allowing the pilot to adapt to actual conditions.
- Intervene: Collect samples, cut lines, attach lifting hardware or perform another approved task.
Before committing to this approach, confirm that the two systems use compatible coordinate frames and datums, that target positions can be transferred into the ROV navigation system, and that the vessel can support both launch-and-recovery cycles. Integration, communications, navigation and deck handling should be verified with the system vendor or marine robotics integrator.
A practical decision process
- Define the deliverable. Is the output a map or sensor dataset, a live visual inspection, a recovered object, a sample, a cut line or an installed lifting hook? A map favors an AUV; physical outcomes favor an ROV.
- Decide whether a delayed view is acceptable. If the team can wait until recovery to see the images and measurements, autonomous logging is possible. If someone must react immediately, use a live ROV link.
- Measure the intervention requirement. List every required contact with the target, including grasping, turning, cutting, lifting or tool placement. Any such requirement should be treated as an ROV or specialized intervention-vehicle requirement unless the AUV has a documented capability.
- Map the operating area. Long transects and open seabed reduce the value of a tether. Dense structures, wreckage and lines increase the importance of pilot control but also raise tether-entanglement risk.
- Check depth and conditions. Confirm pressure rating, temperature range, corrosion protection, current limits, visibility assumptions and sensor performance for the actual site, not just the vehicle family name.
- Plan navigation and recovery. An AUV plan must specify launch position, acoustic or inertial navigation aids if used, abort behavior, surfacing location, tracking and recovery procedures. An ROV plan must specify launch equipment, tether routing, pilot station and a recovery response for a fouled or damaged umbilical.
- Build the vessel and crew plan. Match deck space, crane or A-frame capacity, power, handling equipment, pilot seats, tether technicians, survey staff and safety procedures to the selected system.
- Compare the complete mission cost. Include mobilization, vessel days, pilots, survey processing, tooling, launch and recovery, weather delays, maintenance and the cost of repeating a dive if the first run cannot answer the question.
How control, data and navigation shape operations
AUV mission execution
An AUV operator turns the objective into a mission file: waypoints or survey lines, depth or altitude, speed, sensor triggers, communications windows, minimum-battery rules and emergency actions. Once submerged, the vehicle may have only limited ability to receive changes. The team therefore needs tested simulations, conservative abort thresholds and a recovery plan that works if the vehicle deviates from its track.
Data management begins before launch. Set file formats, sensor time synchronization, storage capacity, calibration records and quality-control checks. After recovery, inspect the vehicle, copy data using a controlled workflow and compare navigation logs with the planned track before accepting the survey.
ROV mission execution
An ROV pilot works from live video and instruments, often with a second operator managing cameras, sonar or tooling. The vessel’s position, current and tether shape affect the vehicle’s ability to hold station. The pilot and tether team need agreed calls for slack, tension, thruster limits, obstacle clearance and emergency ascent or recovery.
Live data does not guarantee perfect visibility. Turbidity, darkness, glare, backscatter and camera placement can hide a feature. Lighting, sonar and a stable vehicle attitude may be as important as camera resolution. Record the vehicle position, heading, depth and time with each inspection observation so findings can be revisited.
Rank #3

- The FIFISH V6 EXPERT comes standard with the FIFISH V6 EXPERT ROV, tether reel, remote controller, and chargers. Essential differences between the packages include: M100 Package: EPP Box Packaging, with 330ft Tether Reel; M200 Package: Industrial Case Packaging, with 660ft Tether Reel; M100A Package: Industrial Case Packaging, Robotic Arm, with 330ft Tether Reel; M200A Package: Industrial Case Packaging, Robotic Arm, with 660ft Tether Reel.
- Extend & Enhance Your Dives: FIFISH V6 EXPERT underwater drone equipped with 14400mAh battery, working time up to 6 hours. And deliver quick charging capabilities to reach 90% of charging capacity in just 1 hour. Integrate with the Onshore Power Supply System to achieve uninterrupted diving sessions.
- Upgraded Build & Performance: In addition to its patented omnidirectional movement and 360° manuverability, FIFISH V6 EXPERT underwater drone delivers an upgraded motor system, with full protection of its core components against corrosion, and enhanced stability for a seamless operating experience.
- Upgraded Build & Performance: In addition to its patented omnidirectional movement and 360° manuverability, FIFISH V6 EXPERT underwater drone delivers an upgraded motor system, with full protection of its core components against corrosion, and enhanced stability for a seamless operating experience.
- Seamless Video & Image Transfers: With a built-in quick plug compartment, a Micro SD card can be inserted and removed to easily transport data and images out of the V6 EXPERT. The ROV comes equipped with a 128GB card for ample space and storage of high-definition films and images.
Depth, pressure and environmental constraints
Every underwater robot faces pressure, cold, darkness, corrosion and limited communication. NOAA’s Ocean Exploration technology material notes that pressure reaches about 596 atmospheres at 6,000 meters (2023 context). That pressure affects housings, connectors, oil compensation, batteries, sensors and manipulators. A vehicle rated for a certain depth is not automatically suitable for the temperature, current, salinity or bottom conditions at that depth.
Acoustic communication can be slow and intermittent compared with a surface radio link. An AUV should therefore be able to complete essential behavior without a continuous command channel. An ROV has a physical communications path, but the tether, connectors and topside electronics still require inspection and environmental protection.
- Confirm the rated working depth, test depth and any restrictions for the installed payload.
- Check current and sea-state limits for launch, recovery and station keeping.
- Verify material compatibility and corrosion controls for the site’s salinity and contaminants.
- Ask how the system behaves after a leak, power fault, navigation drop-out or tether failure.
- Match lights, cameras and sonar to expected visibility rather than relying on daylight assumptions.
Payloads and physical work
An AUV’s payload bay is normally optimized for sensing: imaging sonar, multibeam or side-scan sonar, cameras, navigation instruments and environmental probes. Adding a sensor can reduce endurance through power draw, drag or processing load. Verify mounting, time synchronization, calibration, data storage and whether the vehicle can maintain altitude or speed with the package installed.
An ROV can carry similar sensors while adding manipulators, tool skids and task-specific equipment. A manipulator’s number of functions does not by itself describe useful capability. Check reach, joint motion, grip force, tooling compatibility, hydraulic or electrical interfaces, camera views and the pilot controls required. For lifting or recovery, obtain a rated load path that includes the frame, manipulator or hook, tether and attachment hardware; do not infer capacity from a vehicle’s marketing class.
Vessel, launch and recovery requirements
An AUV needs a safe way to enter and leave the water, a method to track it, deck space for batteries and data handling, and a recovery crew prepared for weather or a delayed surfacing event. Some missions need acoustic positioning or a support boat. Recovery is part of the mission design, not an afterthought: a perfectly collected dataset has little value if the vehicle cannot be found or brought aboard.
An ROV operation adds a tether-management system, launch-and-recovery equipment, a pilot control room, power distribution and personnel who can monitor umbilical loads and routing. Vessel size and crane geometry can limit which ROV can be deployed safely. Confirm deck load ratings, overboarding points, emergency release procedures and the vessel’s ability to maintain position over the worksite.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.What “ROV” can mean in practice: the CURV-21 example
The U.S. Navy’s CURV-21 demonstrates why “ROV” is not synonymous with a small recreational underwater camera. Its fact sheet lists a weight of 6,400 pounds, a rating to 20,000 feet of seawater, CTFM sonar, multiple cameras, two seven-function manipulators and a 4,000-pound lift capacity through the ROV frame and umbilical. The system can accept configurable salvage or instrument packages.
Free tools Windows power users keep installed
One-click scans. No signup required.
Those figures describe that particular work-class vehicle, not an industry-wide ROV specification. A small inspection ROV may have no manipulator, a much shallower rating and a different launch method. Procurement should use the current datasheet for the exact vehicle, configuration and payload.
Rank #4

- 【More clearer And More Stable】GLADIUS MINI S captures epic moments with 4K HD video and 12 MP photos. It also comes with a 1/2.3 SONY CMOS, anti-video-shake feature, so you can record the beauty of the mysterious underwater world with more stable and vivid UHD video. With the combination of F2.8 lens and 2 x 1200 lumens LED lights, GLADIUS MINI S underwater drone can capture underwater details even in low light
- 【Up to 4 Hours of Flight Time】Equipped with two 4800 mAh batteries, GLADIUS MINI S underwater drone only takes 3.5H to fully charge the drone, It can reach up to 4 hours of flight time, This will also work for long hours of construction inspections and underwater exploration; In addition, the main unit is equipped with a 64GB SD card, but the GLADIUS MINIS underwater drone can support up to 512GB SD card, making it more convenient for downloading data, while also storing more photos and videos
- 【Move freely in the water】The GLADIUS MINI S underwater drone with camera is equipped with 5 thrusters, a maximum speed of 4 knots; with a maximum depth of 330 ft and a maximum horizontal shooting radius of up to 330 ft; The mini S underwater drone also adopts patented motor technology to prevent rolling in pebbles and sand; It works perfectly and reliably even in complex underwater environments with all patterns to meet your photography, Observing, and work needs at any angle you want
- 【Compatible with Sophisticated Attachments】GLADIUS MINI S underwater drone weighs only 6 lbs. which allow single-person operation and Quick- Deployment within 3 minutes; It supports a variety of mounts such as grabber claw, GoPro camera, etc.; GLADIUS MINI S is an underwater drone that meets the needs of various applications such as underwater photography, scientific exploration, and safety inspection, etc. Ideal for light industrial applications for a wide variety of professionals
- 【Stable Connection Remote Control】Underwater Camera Equip with wired connection remote controller to make the drone able to work stably and continuously without signal disconnections; Depth, temperature, and other parameters can be recorded at the same time; The App also supports live broadcasting or social media sharing, the ability to take photos while recording video, time-lapse photography, as well as quick editing features and HDMI output to other monitors or devices as well as save it on a removable SD card
Crew, support burden and total mission cost
An AUV can reduce the time a vessel must remain over every survey line, but it shifts effort into mission planning, navigation, recovery, battery management and data processing. Specialized survey staff may be needed to validate positioning and sensor quality. A lost-vehicle risk or a failed recovery can erase the apparent savings of a short deployment.
An ROV operation generally carries a larger live support team: pilots, tether technicians, deck crew, survey personnel and specialists for the tooling or inspection scope. Vessel days and weather standby can dominate the budget. The benefit is that the team can identify an issue and act during the same deployment, avoiding a separate dive for confirmation or intervention.
Request a mission-based quotation rather than comparing vehicle purchase prices alone. Ask for assumptions about vessel class, personnel, mobilization, depth, current, weather, data deliverables, tooling, standby, recovery attempts and repeat work.
Quick wins for a faster PC:
Scan for outdated or missing drivers - takes under a minuteDriver Scan →Clear out junk files and repair common Windows errorsFree Scan →Common failure modes and how to prevent them
An AUV finishes the run but the data is unusable
- Run a sensor and navigation calibration check before launch.
- Confirm clock synchronization and adequate storage for the complete mission.
- Use conservative altitude, speed and line spacing for the expected terrain.
- Inspect a sample of data after recovery before demobilizing the vessel.
The AUV cannot be located after surfacing
- Define a tracking method, last-known-position procedure and drift model before launch.
- Set a surfacing area that accounts for wind and current, not just the planned waypoint.
- Carry the recovery equipment, batteries and communications needed for an extended search.
An ROV tether snags
- Survey the structure and seabed for lines, nets, wreckage and protrusions.
- Use a tether-management plan with agreed slack and tension limits.
- Stop thrusting when the tether route is uncertain; pulling harder can worsen the snag or damage the vehicle.
- Document emergency release and recovery actions during the pre-dive briefing.
The ROV cannot perform the planned task
- Verify manipulator reach, grip, force, camera view and tool interfaces with a representative mock-up.
- Check that the installed tooling fits within power, hydraulic, payload and buoyancy limits.
- Allow for poor visibility and currents when estimating how precisely a pilot can position the tool.
Procurement checklist
Before selecting a vehicle or contractor, obtain written answers to these questions:
- What exact deliverable is required: georeferenced map, inspection record, sample, recovered object or completed intervention?
- What depth, temperature, current, visibility and seabed conditions are expected?
- What navigation accuracy and target-position uncertainty are acceptable?
- For an AUV, how are missions uploaded, monitored, aborted, tracked and recovered?
- For an ROV, what live video, sonar, manipulator and tooling capabilities are included?
- What are the launch-and-recovery limits of the proposed vessel?
- Which personnel are supplied, and who is responsible for survey quality control and data processing?
- What happens after a lost communication link, navigation fault, leak, power failure or tether problem?
- Are depth, endurance and payload figures valid for the exact configured system rather than an empty vehicle?
- What data formats, metadata, calibration records and final reports will be delivered?
Bottom-line selection rule
Select an autonomous AUV when coverage, repeatability and untethered sensing are the priority and the vehicle can be recovered after it logs the mission. Select a tethered ROV when a pilot must see, decide and manipulate at the worksite. If you need both a regional map and hands-on confirmation, stage the work: AUV first for detection, ROV second for inspection or intervention. In every case, validate the current vehicle configuration, environmental rating, navigation method, launch-and-recovery arrangement and support plan before deployment.
Frequently Asked Questions
Can an AUV send live video to the surface?
Some AUVs can transmit limited status or low-bandwidth information, but the defining operating pattern is autonomous execution with mission data stored onboard. If continuous, high-quality video is essential, specify a tethered ROV or another system designed for a live data path.
Is an ROV always better for deep water?
No. Depth suitability depends on the exact vehicle, tether, payload and vessel. Deep-water ROVs can support live intervention, while deep-rated AUVs can survey without a tether; compare the configured system’s working depth and environmental limits.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
What if the mission requires both mapping and salvage?
A staged operation is often efficient: map and prioritize targets with an AUV, then deploy an ROV with the cameras, manipulators and lifting equipment needed for confirmation and recovery.
Can a small inspection ROV replace a work-class ROV?
Only when the task fits its depth, station-keeping, camera, manipulator and lifting limits. Work-class capabilities such as those listed for the Navy’s CURV-21 cannot be assumed from the ROV label alone.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

