
Crashes, No Sound, or Screen Glitches?
Random freezes, missing sound and display glitches usually trace back to one bad driver. Find and replace yours safely.Free scan · under a minuteWindows Errors? Fix Them Before They Spread
Repair common Windows errors and clear accumulated junk for a smoother, more stable PC - no reinstall needed.Free scan · no reinstalliTechGuides is reader-supported. When you buy through links on our site, we may earn an affiliate commission. As an Amazon Associate I earn from qualifying purchases. Learn more
Safe Torque Off (STO) prevents a drive from producing motor torque, but it does not electrically isolate the drive or actively brake the motor. The right architecture depends on the drive’s safety inputs and diagnostics, the stopping behavior the machine needs, and the exact product’s documented safety ratings.
What is Safe Torque Off (STO)?
STO is a safety-related drive function that inhibits torque generation. In SEW-EURODRIVE’s documented implementation, activating STO interrupts pulse-width-modulation (PWM) signals so they cannot reach the insulated-gate bipolar transistors (IGBTs) in the output stage. The drive’s supply may remain present. As SEW puts it, STO is used “instead of a galvanic isolation of the drive from the supply system by means of contactors or switches.” ABB’s guide likewise cautions that STO does not protect against electrical hazards. STO is therefore not a substitute for an electrical disconnect or isolation procedure when people must work on electrical equipment.
Does STO stop a motor?
STO removes torque-producing output; it does not command a controlled deceleration. The motor and attached load generally coast according to their inertia, friction, and other mechanical conditions. SEW maps its described STO behavior to stop category 0, an uncontrolled stop. How long the motion continues depends on the application, so STO alone may not satisfy a required stopping time or prevent a hazardous load from moving.
Free tools Windows power users keep installed
One-click scans. No signup required.
When coasting is not acceptable
If the hazard analysis requires controlled deceleration, a defined stopping time, or a load to remain stationary, the machine may need another safety function, braking measures, or both. The design must account for what happens after torque is removed—for example, whether gravity or stored mechanical energy can keep the load moving. A brake is not automatically made safety-related merely because it is present; verify the brake function and its integration in the relevant product documentation and machine-level design.
#1 Best Overall

- Notifier FRM-1 - Control Relay Module
- #1 Supplier for Fire Safety Equipment in North America. Our company is dedicated to help and supply your fire equipment needs with the best prices Worldwide.
- We have the most dedicated customer service team to help you with any question regarding our products and your orders.
Does STO remove power?
STO removes the drive’s ability to produce motor torque; it does not necessarily remove electrical power from the drive, its DC bus, or other equipment. Schneider Electric describes STO as ensuring that “no power that can cause torque or force is supplied to the motor.” That description concerns torque-producing output, not safe electrical isolation. Treat the drive as potentially energized unless the equipment’s specified isolation method has been applied.
How do STO safety architectures differ?
STO is implemented through safety-related inputs and internal or external circuitry, but the details are product-specific. Two documented examples illustrate why a wiring diagram or safety claim for one design cannot be used as a universal recipe.
Rank #2
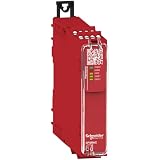
- This safety relay is designed for monitoring Emergency stop and Guard switch
- The safety relay is powered with 24V AC/DC, and equipped with a screw removable terminal block
- This basic safety modules embeds pre-defined safety functions
- This safety relay embeds 1 control output, 4 NO safety outputs, and 2 NC diagnostic outputs
- The maximum safety level achieved by this safety relay is PLe/Category 4 conforming to ISO13849-1, SILCL 3 conforming to IEC62061, SIL 3 conforming to IEC61508
| Documented example | Input and architecture | What the source establishes |
|---|---|---|
| SEW-EURODRIVE safety concept | Two-pole 24 V signal from an external safety controller or relay to the drive’s STO inputs; internal dual-channel structure with diagnostics. | A fault or discrepancy between channels locks PWM output and requires a reset. This describes the cited SEW implementation, not every drive. |
| Texas Instruments TIDA-01599 reference design (2021) | Dual-channel 1oo2 architecture with hardware fault tolerance 1. When both STO inputs are active low, load switches cut primary- and secondary-side supplies to six isolated IGBT gate drivers. | The design guide reports that TÜV SÜD assessed the reference design as generally suitable for SIL 3 and PL e / Category 3. This assessment applies to that design, not automatically to a complete drive or machine. |
An external safety relay or controller can be the physical interface where the selected drive calls for one. The SEW example documents that approach, but it does not establish that a generic relay will work with another manufacturer’s STO input. Check the chosen drive’s manual for its input type and voltage, channel arrangement, diagnostics, fault response, and reset behavior.
What is the difference between STO and SS1?
STO inhibits torque without actively decelerating the motor. Safe Stop 1 (SS1) is relevant when the safety function needs controlled deceleration before torque is removed. ABB describes SS1 as stopping the motor safely and initiating STO below a specified speed or after a defined time. Schneider’s product documentation describes SS1-r as monitored deceleration followed by STO once standstill is reached. These descriptions reflect the cited product documentation; exact implementation depends on the drive.
Rank #3

- 5V Relay Module: Working Voltage: DC 5V; Maximum Load: AC 250V/10A, DC 30V/10A; Trigger Current of Opto-Isolator: 5mA
- Fault-Tolerant Design: Fault Tolerant Design, Even if the Control Line is Broken, the Relay will not Operate;All Interfaces of Relay can be Wired Out Through the Terminals Directly,Normally Open and Normally Closed
- Optocoupler Isolation:1 Channel Relay Board use Optocoupler Isolation that has Strong Driving Ability and Stable Performance ,The Isolation Circuit Prevent Damages to I / O Port by Relay Switch Current
- Jumper Design: The Relay Module has a Jumper That You Can Set Rather the Unit State Changes with High or Low Signal. Has Screw Terminals for Relay (NC,C,NO) and for Input; Coil +, Coil - and Trigger.
- Wide Application: DC 5V Relay Module Works Well with ARM /PIC /AVR /MCU/Raspberry/CNC Machine/ PS4 etc.
SS2, SOS, and SLS
- SS2-r: Schneider describes monitored deceleration followed by Safe Operating Stop (SOS), in which the drive remains enabled to hold position.
- SOS: A safe standstill state in which the drive remains enabled to hold position; it is distinct from removing torque through STO.
- Safe Limited Speed (SLS): Monitors whether motion stays within a speed limit rather than simply removing torque.
These functions address different motion hazards. Do not use “STO” as a synonym for a controlled stop or for holding a load in place.
Does STO need a safety relay?
Not necessarily. The required hardware depends on the selected drive’s architecture and the machine’s safety design. In the SEW example, a two-pole 24 V input comes from an external safety controller or relay. Other designs may have different interface requirements. Before selecting an external device or copying a wiring arrangement, verify the exact drive’s safety manual, input specifications, channel and diagnostic requirements, reset procedure, and applicable certificates.
Rank #4

- SMOKE DETECTOR CONNECTIVITY:SM120X - Interconnect Accessories Smoke Relay Module: 408-SM120X - Smoke Relay Module,Internal power Supply for pull station comparability controls and connects auxiliary warning devices
- FUNCTIONALITY:This module is only activated by a smoke alarm interconnect signal. The relay portion of this module can be used to activate auxiliary warning devices such as external bells and sirens, hallway or stairwell lighting. It provides isolated, (no internal connection to 120 volts AC) normally open, and normally closed contacts.
- COMPATIBILITY:This smoke relay module seamlessly connects with Kidde Fyrnetics devices only and most standard smoke detectors, ensuring reliable integration with your existing home safety system.The model SM120X module is for use with the following interconnectable models: Smoke Alarms: 1235, 1235CA, 1275, 1275CA, 1276, 1276CA, 1285, 1285CA, 1296, i12020, i12020CA, i12040, i1240CA, i12060, i12060CA, i12080, PE120, PE120CA, PI2000, and PI2000CA, RF-SM-ACDC, CO/ Smoke Combo alarms: KN-COSM-IB and KN-COSM-IBCA, and Heat Alarms, HD135F, and HD135FCA, all with red interconnect wires.
- EASE OF USE: Switches connected device power when a smoke/heat interconnect signal is received.Each module is equivalent to one interconnect alarm, reduce the maximum number of interconnect devices by one for each module used. Do not exceed the total number of devices allowable in the interconnect system, refer to the individual alarm owners manual for the maximum number of units allowed when interconnecting. Do not exceed the temperature or humidity limits of +40°F (4.4°C) to 100°F (37.8°C) (such as in garages and unfinished attics) and 90% relative humidity for either the relay module or the alarms.
- USAGE SPECIFICATIONS:408-Sm120x ,Includes: 10 in. Long 18 GA pigtail leads. -Test/reset button. Power Supply portion can be used with manual pull stations, flow switches and spot type heat detectors. Use with interconnected installations. power source: 120 VAC, 60 Hz, .08 amp.
How should STO safety ratings be interpreted?
Safety ratings and failure metrics belong to the specific product, variant, or assessed design named in its documentation. A shared SIL or performance-level claim does not make two architectures interchangeable or establish that the full machine achieves the same rating.
Quick wins for a faster PC:
Scan for outdated or missing drivers - takes under a minuteDriver Scan →Repair Windows errors before they cause bigger problemsFix Now →Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →| Source and scope | Figures stated in the cited documentation | Important boundary |
|---|---|---|
| Texas Instruments, TIDA-01599 reference design, 2021 | Generally suitable for SIL 3 and PL e / Category 3, as reported in the TI guide following TÜV SÜD assessment. | Applies to the named reference design; do not generalize it to another STO circuit, drive, or complete machine. |
| Danfoss guide, 2021, for its stated product families and variants | SIL 2, SIL CL 2, PL d, Category 3, diagnostic coverage 90%, MTTFd 14,000 years, and maximum input-to-output response time 20 ms, with 60 ms for specified variants. | These are product- and variant-specific figures in that guide, not universal STO values. The guide also specifies that the STO signal must be SELV- or PELV-supplied. |
| SEW-EURODRIVE example described above | Specific rating and failure-metric figures are not stated in the cited safety-concept description. | Use the exact drive’s current manual and certificate for its declared values. |
When evaluating a drive, compare more than the headline rating. Check the input architecture, diagnostics and discrepancy response, reset behavior, stopping behavior, response time for the exact variant, and whether the machine needs a separate safety-rated brake function. A machine-level risk assessment determines how those product claims apply to the complete system.
What should an engineer verify in the exact drive documentation?
- Identify the safety function required. Determine whether the hazard calls for torque inhibition, controlled deceleration followed by torque removal, safe standstill, speed monitoring, or a combination.
- Confirm the STO interface. Check the specified supply, input type, number of channels, wiring, and whether an external safety controller or relay is required. Do not assume a 24 V two-pole interface is universal.
- Review fault handling. Find how the drive detects channel faults or discrepancies, what output state it enters, and whether and how a reset is required.
- Read the product-specific safety claims. Match SIL, PL, category, diagnostic coverage, MTTFd, and response time to the precise drive family and variant; note any stated exceptions.
- Check what happens mechanically. Establish whether the load coasts, can fall, or must remain held after torque is removed. Determine whether a separate braking or holding function is needed.
- Use the current product documents and machine-level assessment. Confirm wiring, certificates, and functional-safety design against the selected drive and the machine’s risk assessment rather than relying on a similar model’s example.
Standards and product-specific limits
The product documents cited here explain particular implementations and ratings; they do not establish clause-level requirements or the current edition or jurisdictional adoption of IEC 61800-5-2. For a compliance decision, consult the applicable standard and jurisdictional requirements alongside the current manual and certificate for the exact drive.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

